Category: software released

Visualisation-animation of BSTs, B-Trees and Red-Black-Trees. A modified version of David Galles’ visualisation of BSTs, B-Trees and Red-Black-Trees tree-visualisation A modification of David Galles’ visualisation Manual Insert: Enter one or more numbers between 0 and 999. Separate them with your favorite non-digit character sequence. Press Insert. Delete: Enter a number. Press Delete. Find: Enter a … Read More “Algorithms – Visualisation” »
Erklärung des Codes:

Numerische Lösungsmethoden Numerische Lösungsmethoden für ODEs Vergleich von Euler- und Runge-Kutta-4-Methoden Startzeit (t_start): Endzeit (t_end): Anzahl Schritte (n_steps): Anfangswert (y0): Differentialgleichung (y\’ = f(t, y)): Berechnen und Zeichnen

Gradient Descent Visualisierung Gradient Descent Visualisierung Interaktive Visualisierung des Gradientenabstiegsverfahrens Lernrate (learning_rate): Anzahl Iterationen (iterations): Startwert (initial_w): Kostenfunktion (f(w)): Berechnen und Zeichnen Beispiel:
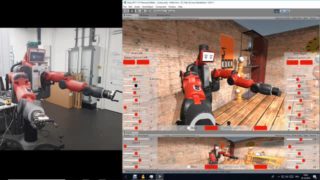
The robot Baxter ist modeled in Unity3D and a UDP interface is implemented for multi process communication. The UDP interface connects also the real robot with the VR-Robot and can be used to either execute learn motion in the VR on the real robot or just to monitor in the VR the executed movements of … Read More “VR Simulation of Baxter” »
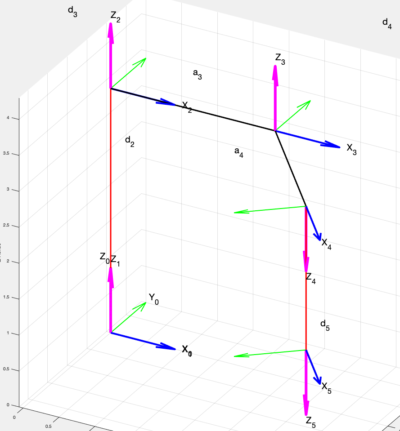
Interactive simulation of the Dennavit Hardenberg convention for open chain manipulators (robot arms)
Matlab simulator implementing the closed form solution for the inverse kinematics problem for multi redundant open chain manipulators. Download-Link: Download MRobot