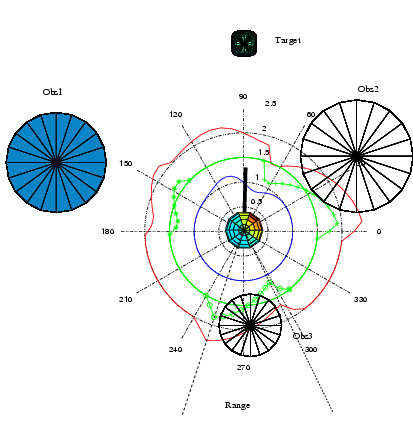
Sebastian Doliwa and Muhammad Ayaz Hussain and Tim Sziburis and Ioannis Iossifidis Timing plays a vital role in the generation of naturalistic behavior satisfying all constraints arising from interacting with a dynamic environment while adapting the planning and execution of action sequences on-line.In biological systems, many of the physiological and anatomical functions follow a particular … Read More “BioRob2022: Biologically Inspired Model for Timed Motion in Robotic Systems” »
Category: teaching
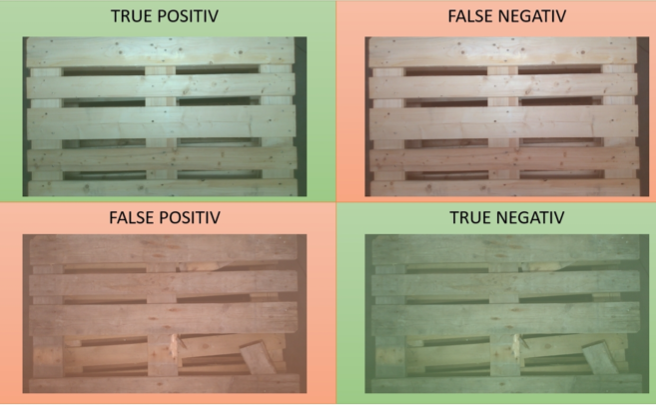
Bachelorarbeitsthema Significance of the proposed Master thesis The use of autonomous vehicles is vital in the manufacturing and distribution operations. The automated guided vehicles (AGVs) provide reliable and efficient product handling in several industrial applications. Goals of the proposed Master thesis In this Master thesis, we are aiming a deep learning-based solution for pallet detection … Read More “Pallets Detection and position tracking for automated guided vehicles” »
Student project within the module “Autonomous Systems” at Ruhr West University of Applied Sciences. Students Tim Büttel, Jonas Peltzer, Pierre Pospiech, Jannik Schremmern Supervision Tim Sziburis, Susanne Blex, Felix Grün, Prof. Dr. Ioannis Iossifidis Project site https://gitlab.hs-ruhrwest.de/iSystemsStudentProjects/2020/eeg-emg-gamecontroller
Wir gratulieren Mohammad Saif-ur-Rehman hat ihre Dissertation an der Fakultät für Informatik der Ruhr-Universität Bochum erfolgreich verteidigt und wurde mit magna cum laude ausgezeichnet. Betreut wurde die Arbeit von Prof. Dr. Ioannis Iossifidis. In seiner Arbeit entwickelte er den „SpikeDeep-Classifier“, einen vollautomatischen Spike-Sortieralgorithmus, der Aktionspotentiale von Neuronen sortiert und klassifiziert. Die Arbeit leistet einen wichtigen … Read More “Erfolgreiche Promotion von Mohammad Saif-ur-Rehman mit magna cum laude – Herzlichen Glückwunsch!🎉🎓✨” »
Student project within the module “Autonomous Systems” at Ruhr West University of Applied Sciences. Students Marvin Maciejewski, Stefan Fohs, Tristan Rienow Supervision Prof. Dr. Ioannis Iossifidis Project site https://gitlab.hs-ruhrwest.de/iSystemsStudentProjects/2020/eeg-emg-gamecontroller live demo
Student project within the module “Autonomous Systems” at Ruhr West University of Applied Sciences. Students Philipp Lösch, Lars Telöken, Ralf Wenzel, Alex Wichmann Supervision Prof. Dr. Ioannis Iossifidis Project site https://gitlab.hs-ruhrwest.de/iSystemsStudentProjects/2020/eeg-emg-gamecontroller live demo
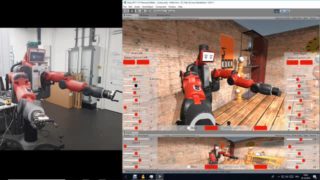
The robot Baxter ist modeled in Unity3D and a UDP interface is implemented for multi process communication. The UDP interface connects also the real robot with the VR-Robot and can be used to either execute learn motion in the VR on the real robot or just to monitor in the VR the executed movements of … Read More “VR Simulation of Baxter” »
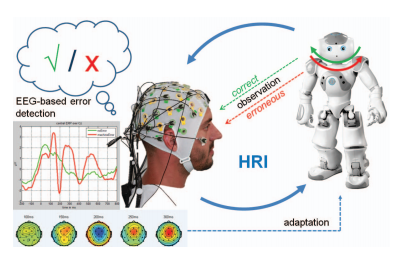
Validating appropriateness and naturalness of human-robot interaction (HRI) is commonly performed by taking subjective measures from human interaction partners, e.g. questionnaire ratings. Although these measures can be of high value for robot designers, they are very sensitive and can be inaccurate and/or biased. In this paper we propose and validate a neuro-based method for objectively … Read More “JournalClub: A neuro-based method for detecting context-dependent erroneous robot action” »
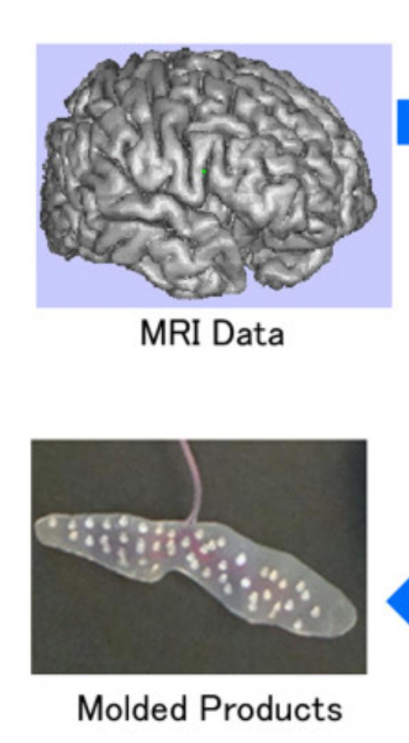
Brain–machine interfaces (BMIs) are promising devices that can be used as neuroprostheses by severely disabled individuals. Brain surface electroencephalograms (electrocorticograms, ECoGs) can provide input signals that can then be decoded to enable communication with others and to control intelligent prostheses and home electronics. However, conventional systems use wired ECoG recordings. Therefore, the development of wireless … Read More “JournalClub: A Fully Implantable Wireless ECoG 128Channel Recording Device for Human Brain–Machine Interfaces” »
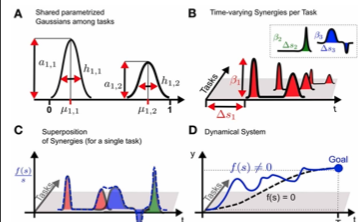
A salient feature of human motor skill learning is the ability to exploit similarities across related tasks. In biological motor control, it has been hypothesized that muscle synergies, coherent activations of groups of muscles, allow for exploiting shared knowledge. Recent studies have shown that a rich set of complex motor skills can be generated by … Read More “JournalClub: Learned parametrized dynamic movement primitives with shared synergies for controlling robotic and musculoskeletal systems” »