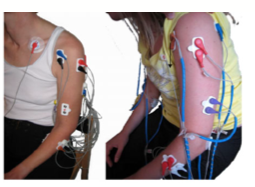
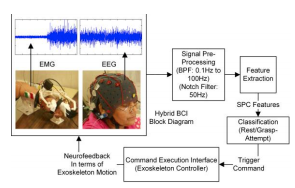
Traditionally a Brain-Computer Interface (BCI) system uses Electroencephalogram (EEG) signals for communication and control applications. In recent years different biological signals are also combined with EEG signals to produce hybrid BCI devices to overcome the limitation of lower accuracy rates in BCI. This paper presents a new approach of combining EEG and Electromyogram (EMG) signals … Read More “JournalClub: EEG-EMG based Hybrid Brain Computer Interface for Triggering Hand Exoskeleton for Neuro-Rehabilitation” »
Category: teaching
In this paper, a novel self-organizing fuzzy neural network is proposed that constructed by an input–output mapping and monitored by a hierarchy of validity degrees. We define new operators called validification and devalidification to propagate validity into the six layers of proposed architecture. Self-organizing in structure learning is accomplished through a new measure that depends … Read More “JournalClub: Introducing validity into self-organizing fuzzy neural network applied to impedance force control” »
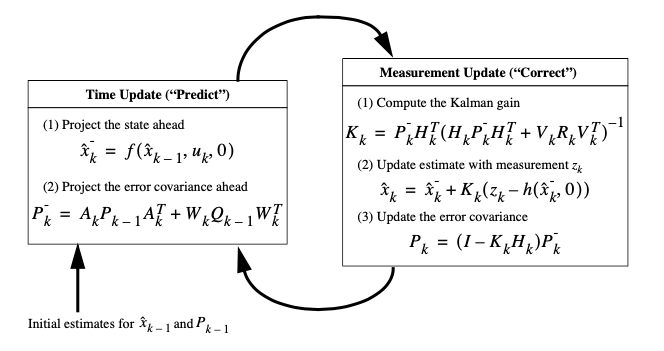
In statistics and control theory, Kalman filtering, also known as linear quadratic estimation (LQE), is an algorithm that uses a series of measurements observed over time, containing statistical noise and other inaccuracies, and produces estimates of unknown variables that tend to be more accurate than those based on a single measurement alone, by estimating a … Read More “JournalClub: An Introduction to Kalman Filter” »
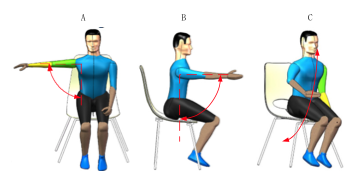
The continuous control of rehabilitation robots based on surface electromyography (sEMG) isa natural control strategy that can ensure human safety and ease the discomfort of human-machine coupling.However, current models for estimating movement of the upper limb focus on two dimensions movement,and models of three dimensions movement are too complex. In this paper, a simple-structure temporalinformation-based … Read More “JournalClub: A Continuous Estimation Model of Upper Limb Joint Angles by Using Surface Electromyography and Deep Learning Method” »
Objective: Stroke is a leading cause of long-term motor disability. Stroke patients with severe hand weakness do not profit from rehabilitative treatments. Recently, brain-controlled robotics and sequential functional electrical stimulation allowed some improvement. However, for such therapies to succeed, it is required to decode patients’ intentions for different arm movements. Here, we evaluated whether residual … Read More “Decoding upper limb residual muscle activity in severe chronic stroke” »
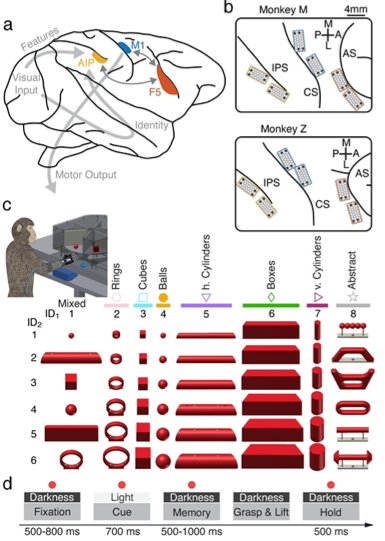
One of the primary ways we interact with the world is using our hands. In macaques, the circuitspanning the anterior intraparietal area, the hand area of the ventral premotor cortex, and the primarymotor cortex is necessary for transforming visual information into grasping movements. Wehypothesized that a recurrent neural network mimicking the multi-area structure of the … Read More “JournalClub: A neural network model of flexible grasp movement generation” »
Artificial neural networks are universal function approximators. They can forecast dynamics, but they may need impractically many neurons to do so, especially if the dynamics is chaotic. We use neural networks that incorporate Hamiltonian dynamics to efficiently learn phase space orbits even as nonlinear systems transition from order to chaos. We demonstrate Hamiltonian neural networks … Read More “JournalClub: Physics-enhanced neural networks learn order and chaos” »
Masterarbeitsthema Abstract: Brain-computer interface (BCI), “the recipe of decoding intended actions from neural signals” is a way forward towards creating an intelligent neuroprosthetics solution. Deep learning (DL) algorithms provide many state-of-the-art results in the rapidly growing BCI applications. Despite this fact, DL algorithms are fragile against synthetic inputs called “adversarial inputs”. These inputs can be … Read More “An investigation of existence of the adversarial inputs in the brain-computer interface (BCI) applications (Thesis proposal)” »
Abstract: A spike sorting algorithm allows the identification of the activity of each neural source. We published two studies SpikeDeeptector and SpikeDeep-Classifier in the journal of the neural engineering. This study is based on our previously published studies. In this study, we aim to identify the neural activity of each source, online. More importantly, we … Read More “Online SpikeDeep-Classifier: The supervised learning based online spike sorting algorithm (Thesis-Proposal)” »
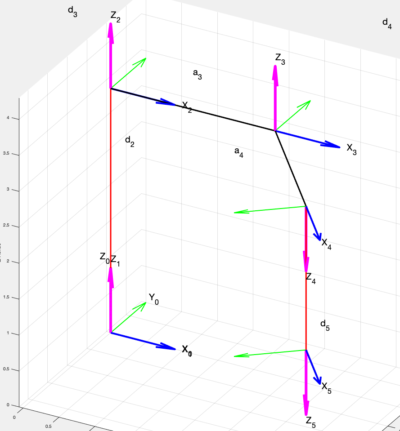
Interactive simulation of the Dennavit Hardenberg convention for open chain manipulators (robot arms)