Skip to content
iLab: From Brain to Machine and Back

iLab: From Brain to Machine and Back

iossifidis Lab

  • Home
  • Research Projects
  • Publications
  • Software
  • Press and Media
  • Student’s Zone — Teaching
    • Thesis topics
    • Student Projects
    • Journal Club & Progress Club
    • Lab Course
    • Lectures – Vorlesungen
  • About us
    • The Team
    • Contact
    • Impressum
  • Home
  • Publications

Publications

Anthropomorphic Robot arm movement model attractor dynamics approach attractor dynamics approach BCI behavior generation collision avoidance direct physical interaction dynamic neural field dynamical systems EEG haptic interface human robot collaboration image processing Inverse kinematics Machine Learning man machine interaction Man-machine-interaction manipulator dynamics movement model recurrent neural network redundant robot arm Reinforcement learning Robot manipulator control Robotics Robotics scene representation simulated reality Simulation speech recognition

Show all

2023

1.
Advancements in Upper Body Exoskeleton: Implementing Active Gravity Compensation with a Feedforward Controller

Muhammad Ayaz Hussain; Ioannis Iossifidis

Advancements in Upper Body Exoskeleton: Implementing Active Gravity Compensation with a Feedforward Controller Journal Article

In: arXiv:2309.04698 [cs.RO], 2023.

Abstract | Links | BibTeX | Tags: Computer Science - Artificial Intelligence, Computer Science - Information Theory, Computer Science - Machine Learning, I.2.6, I.2.8, Quantitative Biology - Neurons and Cognition

@article{ayazhussainAdvancementsUpperBody2023,
title = {Advancements in Upper Body Exoskeleton: Implementing Active Gravity Compensation with a Feedforward Controller},
author = {Muhammad Ayaz Hussain and Ioannis Iossifidis},
url = {https://doi.org/10.48550/arXiv.2309.04698},
doi = {10.48550/arXiv.2309.04698},
year = {2023},
date = {2023-09-09},
urldate = {2023-09-09},
journal = {arXiv:2309.04698 [cs.RO]},
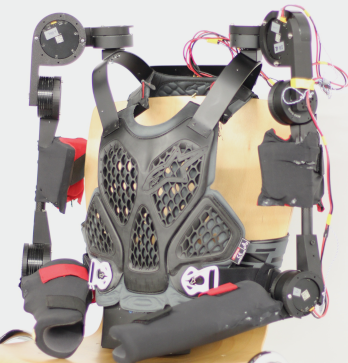
abstract = {In this study, we present a feedforward control system designed for active gravity compensation on an upper body exoskeleton. The system utilizes only positional data from internal motor sensors to calculate torque, employing analytical control equations based on Newton-Euler Inverse Dynamics. Compared to feedback control systems, the feedforward approach offers several advantages. It eliminates the need for external torque sensors, resulting in reduced hardware complexity and weight. Moreover, the feedforward control exhibits a more proactive response, leading to enhanced performance. The exoskeleton used in the experiments is lightweight and comprises 4 Degrees of Freedom, closely mimicking human upper body kinematics and three-dimensional range of motion. We conducted tests on both hardware and simulations of the exoskeleton, demonstrating stable performance. The system maintained its position over an extended period, exhibiting minimal friction and avoiding undesired slewing.},
keywords = {Computer Science - Artificial Intelligence, Computer Science - Information Theory, Computer Science - Machine Learning, I.2.6, I.2.8, Quantitative Biology - Neurons and Cognition},
pubstate = {published},
tppubtype = {article}
}

Close

In this study, we present a feedforward control system designed for active gravity compensation on an upper body exoskeleton. The system utilizes only positional data from internal motor sensors to calculate torque, employing analytical control equations based on Newton-Euler Inverse Dynamics. Compared to feedback control systems, the feedforward approach offers several advantages. It eliminates the need for external torque sensors, resulting in reduced hardware complexity and weight. Moreover, the feedforward control exhibits a more proactive response, leading to enhanced performance. The exoskeleton used in the experiments is lightweight and comprises 4 Degrees of Freedom, closely mimicking human upper body kinematics and three-dimensional range of motion. We conducted tests on both hardware and simulations of the exoskeleton, demonstrating stable performance. The system maintained its position over an extended period, exhibiting minimal friction and avoiding undesired slewing.

Close

  • https://doi.org/10.48550/arXiv.2309.04698
  • doi:10.48550/arXiv.2309.04698

Close

Leave a Reply Cancel reply

Your email address will not be published. Required fields are marked *

Copyright © Ioannis Iossifidis 2020 iLab: From Brain to Machine and Back.

Theme: Oceanly by ScriptsTown

We use cookies on our website to give you the most relevant experience by remembering your preferences and repeat visits. By clicking “Accept All”, you consent to the use of ALL the cookies. However, you may visit "Cookie Settings" to provide a controlled consent.
Cookie SettingsAccept All
Manage consent

Privacy Overview

This website uses cookies to improve your experience while you navigate through the website. Out of these, the cookies that are categorized as necessary are stored on your browser as they are essential for the working of basic functionalities of the website. We also use third-party cookies that help us analyze and understand how you use this website. These cookies will be stored in your browser only with your consent. You also have the option to opt-out of these cookies. But opting out of some of these cookies may affect your browsing experience.
Necessary
Always Enabled
Necessary cookies are absolutely essential for the website to function properly. These cookies ensure basic functionalities and security features of the website, anonymously.
CookieDurationDescription
cookielawinfo-checkbox-analytics11 monthsThis cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Analytics".
cookielawinfo-checkbox-functional11 monthsThe cookie is set by GDPR cookie consent to record the user consent for the cookies in the category "Functional".
cookielawinfo-checkbox-necessary11 monthsThis cookie is set by GDPR Cookie Consent plugin. The cookies is used to store the user consent for the cookies in the category "Necessary".
cookielawinfo-checkbox-others11 monthsThis cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Other.
cookielawinfo-checkbox-performance11 monthsThis cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Performance".
viewed_cookie_policy11 monthsThe cookie is set by the GDPR Cookie Consent plugin and is used to store whether or not user has consented to the use of cookies. It does not store any personal data.
Functional
Functional cookies help to perform certain functionalities like sharing the content of the website on social media platforms, collect feedbacks, and other third-party features.
Performance
Performance cookies are used to understand and analyze the key performance indexes of the website which helps in delivering a better user experience for the visitors.
Analytics
Analytical cookies are used to understand how visitors interact with the website. These cookies help provide information on metrics the number of visitors, bounce rate, traffic source, etc.
Advertisement
Advertisement cookies are used to provide visitors with relevant ads and marketing campaigns. These cookies track visitors across websites and collect information to provide customized ads.
Others
Other uncategorized cookies are those that are being analyzed and have not been classified into a category as yet.
SAVE & ACCEPT