

Publications
2026
Marie D. Schmidt; Ioannis Iossifidis
The Spatial and~Temporal Resolution of~Motor Intention in~Multi-target Prediction Inproceedings
In: Neumann, Philipp; Puma, Michael J.; Lees, Michael H.; Groen, Derek; Dongarra, Jack J.; Sloot, Peter M. A. (Ed.): Computational Science – ICCS 2026, pp. 421–428, Springer Nature Switzerland, Cham, 2026, ISBN: 978-3-032-29924-6.
Abstract | Links | BibTeX | Tags: BCI, EMG, HMI, Motor control, Random Forest
@inproceedings{schmidtSpatialTemporalResolution2026,

title = {The Spatial and~Temporal Resolution of~Motor Intention in~Multi-target Prediction},

author = {Marie D. Schmidt and Ioannis Iossifidis},

editor = {Philipp Neumann and Michael J. Puma and Michael H. Lees and Derek Groen and Jack J. Dongarra and Peter M. A. Sloot},

doi = {10.1007/978-3-032-29924-6_36},

isbn = {978-3-032-29924-6},

year  = {2026},

date = {2026-06-27},

urldate = {2026-06-27},

booktitle = {Computational Science – ICCS 2026},

pages = {421–428},

publisher = {Springer Nature Switzerland},

address = {Cham},

abstract = {Reaching, grasping, and object manipulation are essential motor functions in everyday life. This study predicts movement direction and target location from multichannel electromyography (EMG) signals, examining how spatially and temporally accurate intentions can be detected relative to movement onset. A computational pipeline combining data-driven temporal segmentation with Random Forest model is applied to EMG data across planning, execution, and contact phases of a reaching task.},

keywords = {BCI, EMG, HMI, Motor control, Random Forest},

pubstate = {published},

tppubtype = {inproceedings}

}
Felix Grün; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis
Invariance to~Quantile Selection in~Distributional Continuous Control Inproceedings
In: Nicosia, Giuseppe; Ojha, Varun; Giesselbach, Sven; Pardalos, M. Panos; Umeton, Renato; Emanuele, La Malfa; Gabriele, La Malfa (Ed.): Machine Learning, Optimization, and Data Science, pp. 175–190, Springer Nature Switzerland, Cham, 2026, ISBN: 978-3-032-21477-5.
Abstract | Links | BibTeX | Tags: Actor-critic, BCI, Continuous control, Distributional reinforcement learning, Machine Learning, Quantile regression, reinforcement learning (RL)
@inproceedings{grunInvarianceQuantileSelection2026,

title = {Invariance to~Quantile Selection in~Distributional Continuous Control},

author = {Felix Grün and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis},

editor = {Giuseppe Nicosia and Varun Ojha and Sven Giesselbach and M. Panos Pardalos and Renato Umeton and La Malfa Emanuele and La Malfa Gabriele},

doi = {10.1007/978-3-032-21477-5_12},

isbn = {978-3-032-21477-5},

year  = {2026},

date = {2026-06-01},

urldate = {2026-06-01},

booktitle = {Machine Learning, Optimization, and Data Science},

pages = {175–190},

publisher = {Springer Nature Switzerland},

address = {Cham},

abstract = {In recent years, distributional reinforcement learning has produced many state-of-the-art results in typical reinforcement learning benchmarks, such as the suite of Atari games. Increasingly sample-efficient distributional algorithms for the discrete action domain have been developed over time, which vary primarily in the way they parameterize their approximations of value distributions, and how they quantify the differences between those distributions. In this work, we transfer three of those algorithms - Quantile Regression Deep Q-Network (QR-DQN), Implicit Quantile Networks (IQN) and Fully Parameterized Quantile Function (FQF) - to the continuous action domain by extending two powerful actor-critic algorithms - Twin Delayed Deep Deterministic policy gradient (TD3) and Soft Actor-Critic (SAC) - with distributional critics. We investigate whether the relative performance of the methods for the discrete action space translates to the continuous case. To that end, we compare them empirically on a set of continuous control tasks (Ant, HalfCheetah, Hopper, Humanoid and Walker2D). Our results indicate qualitative invariance regarding the number and placement of distributional atoms in the deterministic, continuous action setting.},

keywords = {Actor-critic, BCI, Continuous control, Distributional reinforcement learning, Machine Learning, Quantile regression, reinforcement learning (RL)},

pubstate = {published},

tppubtype = {inproceedings}

}
Stephan Johann Lehmler; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis
Distributional Properties of~ReLU-Activations in~Artificial Neural Networks That~Learn by~Memorization Inproceedings
In: Nicosia, Giuseppe; Ojha, Varun; Giesselbach, Sven; Pardalos, M. Panos; Umeton, Renato; Emanuele, La Malfa; Gabriele, La Malfa (Ed.): Machine Learning, Optimization, and Data Science, pp. 410–423, Springer Nature Switzerland, Cham, 2026, ISBN: 978-3-032-21477-5.
Abstract | Links | BibTeX | Tags: Artificial neural networks, BCI, Machine Learning, Memorization, Statistical Modeling
@inproceedings{lehmlerDistributionalPropertiesReLUActivations2026,

title = {Distributional Properties of~ReLU-Activations in~Artificial Neural Networks That~Learn by~Memorization},

author = {Stephan Johann Lehmler and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis},

editor = {Giuseppe Nicosia and Varun Ojha and Sven Giesselbach and M. Panos Pardalos and Renato Umeton and La Malfa Emanuele and La Malfa Gabriele},

doi = {10.1007/978-3-032-21477-5_27},

isbn = {978-3-032-21477-5},

year  = {2026},

date = {2026-06-01},

urldate = {2026-06-01},

booktitle = {Machine Learning, Optimization, and Data Science},

pages = {410–423},

publisher = {Springer Nature Switzerland},

address = {Cham},

abstract = {We investigate the distributional properties of layers in Artificial Neural Network (ANN) that can be used to distinguish between networks learning by generalization and memorizing networks. Starting from the notion of memorization being essentially definable as learning ‘rare’ features of the input data, we propose the activation probability of Rectified Linear Units (ReLU)-neurons as an important indicator of memorization. Building on this idea, we show how hypotheses about distributional properties over whole networks structures can be derived from the activation probability of singular neurons in memorizing ANNs. We such extend previous work on using Poisson process models of activations in ANN by considering the correlation between neurons. Using this approach, we further simulate the effect of memorizing neurons on distributional properties of weight matrices and activation magnitudes and find a connection between L1/L2-norm regularization of weight matrices. We empirically evaluate the distributions of activation rate, correlation structure and weight matrices in memorizing and generalizing ANNs on a simple MNIST-classification task. Our initial findings show how the activation frequency and intra-layer correlation structure can be used to distinguish generalizing from memorizing networks and for inferring distributional properties on affected parts of the networks. This work presents a building block to later derive online metrics for memorization in ANNs.},

keywords = {Artificial neural networks, BCI, Machine Learning, Memorization, Statistical Modeling},

pubstate = {published},

tppubtype = {inproceedings}

}
Aline Xavier Fidêncio; Felix Grün; Christian Klaes; Ioannis Iossifidis
Performance Boundaries for~Brain-Computer Interfaces Using Error-Related Potentials and~Reinforcement Learning Inproceedings
In: Nicosia, Giuseppe; Ojha, Varun; Giesselbach, Sven; Pardalos, M. Panos; Umeton, Renato; Emanuele, La Malfa; Gabriele, La Malfa (Ed.): Machine Learning, Optimization, and Data Science, pp. 335–349, Springer Nature Switzerland, Cham, 2026, ISBN: 978-3-032-21480-5.
Abstract | Links | BibTeX | Tags: adaptive brain-computer interface, BCI, electroencephalography (EEG), error-related potentials (ErrPs), Machine Learning, motor imagery (MI), reinforcement learning (RL)
@inproceedings{xavierfidencioPerformanceBoundariesBrainComputer2026,

title = {Performance Boundaries for~Brain-Computer Interfaces Using Error-Related Potentials and~Reinforcement Learning},

author = {Aline Xavier Fidêncio and Felix Grün and Christian Klaes and Ioannis Iossifidis},

editor = {Giuseppe Nicosia and Varun Ojha and Sven Giesselbach and M. Panos Pardalos and Renato Umeton and La Malfa Emanuele and La Malfa Gabriele},

doi = {10.1007/978-3-032-21480-5_23},

isbn = {978-3-032-21480-5},

year  = {2026},

date = {2026-06-01},

urldate = {2026-06-01},

booktitle = {Machine Learning, Optimization, and Data Science},

pages = {335–349},

publisher = {Springer Nature Switzerland},

address = {Cham},

abstract = {Non-invasive brain-computer interfaces (BCIs) can improve quality of life for individuals with motor disabilities. However, input data non-stationarity often leads to performance degradation over time. Adaptive BCIs aim to address this challenge. Recent studies have proposed leveraging error-related potentials (ErrPs) - neural signals elicited during self-made or observed errors - as a natural feedback mechanism for closed-loop systems. While these approaches demonstrate potential performance gains, their effectiveness relies heavily on accurate ErrP detection, which remains challenging. In a previous study, we introduced a novel reinforcement learning-based BCI framework incorporating ErrPs as reward signals. We systematically examine how misclassification rates in ErrP detection in terms of false positives (FPs) and false negatives (FNs) influence closed-loop performance. We use both synthetic and real datasets to evaluate two contextual bandit algorithms (LinUCB and NeuralUCB), trained to map motor imagery-related time-frequency modulations to actions in a binary task. Firstly, our findings show that the sensitivity of agents to FPs and FNs depends on baseline accuracies. In some conditions, such as insufficient exploration, false negatives might be more detrimental than false positives, but this needs further investigation. Proper agent parametrization and enough data samples can compensate the negative effects to some extent.},

keywords = {adaptive brain-computer interface, BCI, electroencephalography (EEG), error-related potentials (ErrPs), Machine Learning, motor imagery (MI), reinforcement learning (RL)},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Ioannis Iossifidis
The Spatial and Temporal Resolution of Motor Intention in Multi-Target Prediction Journal Article
In: arXiv:2603.05418 [q-bio.NC], 2026.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning, Motor control
@article{schmidt2026spatialtemporalresolutionmotor,

title = {The Spatial and Temporal Resolution of Motor Intention in Multi-Target Prediction},

author = {Marie Dominique Schmidt and Ioannis Iossifidis},

url = {https://arxiv.org/abs/2603.05418},

doi = {https://doi.org/10.48550/arXiv.2603.05418},

year  = {2026},

date = {2026-03-05},

urldate = {2026-03-05},

journal = {arXiv:2603.05418 [q-bio.NC]},

abstract = {Reaching for grasping, and manipulating objects are essential motor functions in everyday life. Decoding human motor intentions is a central challenge for rehabilitation and assistive technologies. This study focuses on predicting intentions by inferring movement direction and target location from multichannel electromyography (EMG) signals, and investigating how spatially and temporally accurate such information can be detected relative to movement onset. We present a computational pipeline that combines data-driven temporal segmentation with classical and deep learning classifiers in order to analyse EMG data recorded during the planning, early execution, and target contact phases of a delayed reaching task.

Early intention prediction enables devices to anticipate user actions, improving responsiveness and supporting active motor recovery in adaptive rehabilitation systems. Random Forest achieves 80% accuracy and Convolutional Neural Network 75% accuracy across 25 spatial targets, each separated by 14∘ azimuth/altitude. Furthermore, a systematic evaluation of EMG channels, feature sets, and temporal windows demonstrates that motor intention can be efficiently decoded even with drastically reduced data. This work sheds light on the temporal and spatial evolution of motor intention, paving the way for anticipatory control in adaptive rehabilitation systems and driving advancements in computational approaches to motor neuroscience.},

keywords = {BCI, Machine Learning, Motor control},

pubstate = {published},

tppubtype = {article}

}
Early intention prediction enables devices to anticipate user actions, improving responsiveness and supporting active motor recovery in adaptive rehabilitation systems. Random Forest achieves 80% accuracy and Convolutional Neural Network 75% accuracy across 25 spatial targets, each separated by 14∘ azimuth/altitude. Furthermore, a systematic evaluation of EMG channels, feature sets, and temporal windows demonstrates that motor intention can be efficiently decoded even with drastically reduced data. This work sheds light on the temporal and spatial evolution of motor intention, paving the way for anticipatory control in adaptive rehabilitation systems and driving advancements in computational approaches to motor neuroscience.
Marie D. Schmidt; Tobias Glasmachers; Ioannis Iossifidis
Insights into Motor Control: Predict Muscle Activity from Upper Limb Kinematics with LSTM Networks Journal Article
In: Nature Scientific Reports, 2026, ISSN: 2045-2322.
Abstract | Links | BibTeX | Tags: BCI, Computational biology and bioinformatics, Motor control, Neuroscience
@article{schmidtInsightsMotorControl2026,

title = {Insights into Motor Control: Predict Muscle Activity from Upper Limb Kinematics with LSTM Networks},

author = {Marie D. Schmidt and Tobias Glasmachers and Ioannis Iossifidis},

editor = {Nature Publishing Group},

url = {https://www.nature.com/articles/s41598-025-33696-y},

doi = {10.1038/s41598-025-33696-y},

issn = {2045-2322},

year  = {2026},

date = {2026-01-05},

urldate = {2026-01-05},

journal = {Nature Scientific Reports},

publisher = {Nature Publishing Group},

abstract = {This study explores the relationship between upper limb kinematics and corresponding muscle activity, aiming to understand how predictive models can approximate motor control. We employ a Long Short-Term Memory (LSTM) network trained on kinematic end effector data to estimate muscle activity for eight muscles. The model exhibits strong predictive accuracy for new repetitions of known movements and generalizes to unseen movements, suggesting it captures underlying biomechanical principles rather than merely memorizing patterns. This generalization is particularly valuable for applications in rehabilitation and human-machine interaction, as it reduces the need for exhaustive datasets. To further investigate movement representation and learning, we analyze the impact of motion segmentation, hypothesizing that breaking movements into simpler components may improve model performance. Additionally, we explore the role of the swivel angle in reducing redundancy in arm kinematics. Another key focus is the effect of training data complexity on generalization. Specifically, we assess whether training on a diverse set of movements leads to better performance than specializing in either simple, single-joint movements or complex, multi-joint movements. The study is based on an experimental setup involving 23 distinct upper limb movements performed by five subjects. Our findings provide insights into the interplay between kinematics and muscle activity, contributing to motor control research and advancing neural network-based movement prediction.},

keywords = {BCI, Computational biology and bioinformatics, Motor control, Neuroscience},

pubstate = {published},

tppubtype = {article}

}
2025
Felix Grün; Ioannis Iossifidis
A Framework to Model Your Model Based / Model Free Action Selection Hypothesis Inproceedings
In: BC25 : Bernstein Conference 2025,, BCCN Bernstein Network Computational Neuroscience & Neurotechnology, 2025.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning, Reinforcement learning
@inproceedings{grunFrameworkModelYour2025,

title = {A Framework to Model Your Model Based / Model Free Action Selection Hypothesis},

author = {Felix Grün and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC25/abstracts#/uuid/e3090016-2d82-4107-b587-1474f97be0b3},

year  = {2025},

date = {2025-10-01},

urldate = {2025-10-01},

booktitle = {BC25 : Bernstein Conference 2025,},

publisher = {BCCN Bernstein Network Computational Neuroscience & Neurotechnology},

abstract = {Dopaminergic Reward Prediction Errors (RPEs) are a key motivation and inspiration for model free, temporal difference reinforcement learning methods. Originally, the correlation of RPEs with model free temporal difference errors was seen as a strong indicator for model free reinforcement learning in brains. The standard view was that model free learning is the norm and more computationally expensive model based decision-making is only used when it leads to outcomes that are good enough to justify the additional effort. Nowadays, the landscape of opinions, models and experimental evidence, both electrophysiological and behavioral, paints a more complex picture, including but not limited to mechanisms of arbitration between the two systems. Model based learning or hybrid models better capture experimental behavioral data, and model based signatures are found in RPEs that were previously thought to be model free or hybrid [1]. The evidence for clearly model free learning is scarce [2]. On the other hand, multiple approaches show how model based behavior and RPEs can be produced with fundamentally model free reinforcement learning methods [3, 4, 5]. We point out findings that seem to contradict each other, others that complement each other, speculate which ideas are compatible with each other and give our opinions on ways forward, towards understanding if and how model based and model free learning from rewards coexist and interact in the brain.},

keywords = {BCI, Machine Learning, Reinforcement learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Ioannis Iossifidis
Predicting Upper Limb Muscle Activity from Kinematics Using LSTM Networks Inproceedings
In: Bernstein Conference 2025, BCCN Bernstein Network Computational Neuroscience & Neurotechnology, 2025.
Abstract | Links | BibTeX | Tags: BCI
@inproceedings{schmidtPredictingUpperLimb2025,

title = {Predicting Upper Limb Muscle Activity from Kinematics Using LSTM Networks},

author = {Marie Dominique Schmidt and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC25/abstracts#/uuid/a8fa799f-bf8e-4192-8ba9-3b1e3ad078ea},

year  = {2025},

date = {2025-10-01},

urldate = {2025-10-01},

booktitle = {Bernstein Conference 2025},

publisher = {BCCN Bernstein Network Computational Neuroscience & Neurotechnology},

abstract = {The upper limbs are essential for performing everyday tasks that require a wide range of motion and precise coordination. Planning and timing are crucial to achieve coordinated movement. Sensory information about the target and current body state is critical, as is the integration of prior experience represented by prelearned inverse dynamics that generate the associated muscle activity. We propose a generative model that uses a recurrent neural network to predict upper limb muscle activity during various simple and complex everyday movements. By identifying movement primitives within the signal, our model enables the decomposition of these movements into a fundamental set, facilitating the reconstruction of muscle activity patterns. Our approach has implications for the fundamental understanding of movement control and the rehabilitation of neuromuscular disorders with myoelectric prosthetics and functional electrical stimulation.},

keywords = {BCI},

pubstate = {published},

tppubtype = {inproceedings}

}
Aline Xavier Fidencio; Ioannis Iossifidis
Error-Related Potentials and Reinforcement Learning for Neuroadaptive Systems Inproceedings
In: BC25 : Bernstein Conference 2025,, BCCN Bernstein Network Computational Neuroscience & Neurotechnology, 2025.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning
@inproceedings{xavierfidencioErrorrelatedPotentialsReinforcement2025,

title = {Error-Related Potentials and Reinforcement Learning for Neuroadaptive Systems},

author = {Aline Xavier Fidencio and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC25/abstracts#/uuid/84a56344-585c-4d7c-992d-1f34489770f5},

year  = {2025},

date = {2025-10-01},

urldate = {2025-10-01},

booktitle = {BC25 : Bernstein Conference 2025,},

publisher = {BCCN Bernstein Network Computational Neuroscience & Neurotechnology},

abstract = {Error-related potentials (ErrPs) represent the neural signature of error processing in the brain and numerous studies have demonstrated their reliable detection using non-invasive techniques such as electroencephalography (EEG). Over recent decades, the brain-computer interface (BCI) community has shown growing interest in leveraging these intrinsic feedback signals to enhance system performance. However, the effective use of ErrPs in a closed-loop setup crucially depends on accurate single-trial detection, which is typically achieved using a subject-specific classifier (or decoder) trained on samples recorded during extensive calibration sessions before the BCI system can be deployed. In our research, we explore the potential of simulated EEG data for training a truly generic ErrP classifier. Utilizing the SEREEGA simulator, we demonstrate that EEG data can be generated in a cost-effective manner, allowing for controlled and systematic variations in data distribution to accommodate uncertainties in ErrP generation. A classifier trained solely on the generated data exhibits promising generalization capabilities across different datasets and performs comparably to a leave-one-subject-out approach trained on real data (Xavier Fidêncio et al., 2024). In our experiments, we deliberately provoked ErrPs when the BCI misinterpreted the user's intention, resulting in incorrect actions. Subjects engaged in a game controlled via keyboard and/or motor imagery (imagining hand movements), with EEG data recorded using various EEG systems for comparison. Considering the challenges in obtaining clear ErrP signals for all subjects and the limitations identified in existing literature (Xavier Fidêncio et al., 2022), we hypothesize whether a measurable error signal is consistently generated at the scalp level when subjects encounter erroneous conditions, and how this influences closed-loop setups that incorporate ErrPs for improved BCI performance. To address these questions, we assess the effects of the occurrence-to-detection ratio of ErrPs in the classification pipeline using simulated data and explore the impact of error misclassification rates in an ErrP-based learning framework, which employs reinforcement learning to enhance BCI performance.},

keywords = {BCI, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Stephan Johann Lehmler; Muhammad Saif Rehman; Ioannis Iossifidis
Activation-Based Indicators of Memorization in ReLU Artificial Neural Networks: A Computational Perspective Inproceedings
In: BC25 : Bernstein Conference 2025, BCCN Bernstein Network Computational Neuroscience & Neurotechnology, 2025.
Abstract | Links | BibTeX | Tags: Machine Learning
@inproceedings{lehmlerActivationBasedIndicatorsMemorization2025,

title = {Activation-Based Indicators of Memorization in ReLU Artificial Neural Networks: A Computational Perspective},

author = {Stephan Johann Lehmler and Muhammad Saif Rehman and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC25/abstracts#/uuid/cfc1121c-9d2c-4017-a781-15e9ec615053},

year  = {2025},

date = {2025-09-30},

urldate = {2025-09-30},

booktitle = {BC25 : Bernstein Conference 2025},

publisher = {BCCN Bernstein Network Computational Neuroscience & Neurotechnology},

abstract = {Our recent work presents a stochastic process model of the activations within an ANN and shows a promising indicator to distinguish memorizing from generalizing ANNs. The average λ, or mean firing rate (MFR), of a hidden layer, shows stable differences between memorizing and generalizing networks, comparatively independent of the underlying data used for evaluation. We first show the performance of this indicator during training on benchmark computer vision datasets such as MNIST and CIFAR-10. In a second step, we extend the work to the real-life use case of calibrating a pre-trained model to a new user. We focus on decoding surface electromyographic (sEMG) signals, which are highly variable within and between users, and therefore necessitate frequent user calibration. Especially in situations when user calibration has to only rely on a small number of samples, degradation in performance overtime due to memorization and overfitting is a not unlikely outcome. In those cases, traditional regularization methods that function by observing the performance on a validation set, such as early stopping, don’t necessarily work, because they are evaluated on data from the same subject and set of movements, which features are being memorized. Our new indicators of memorization could help as stable indicators for model performance and give live insights during model calibration when more samples from the new users would be necessary. We evaluate the usefulness of the MFR-indicator for identifying the moment a pre-trained sEMG decoder starts to memorize given inputs},

keywords = {Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Muhammad Saif-ur-Rehman; Omair Ali; Christian Klaes; Ioannis Iossifidis
Adaptive SpikeDeep-classifier: Self-organizing and Self-Supervised Machine Learning Algorithm for Online Spike Sorting Journal Article
In: Neurocomputing, pp. 131370, 2025, ISSN: 0925-2312.
Abstract | Links | BibTeX | Tags: BCI, Brain computer interface, Deep learning, Self organizing, Self-supervised machine learning, Spike Sorting
@article{saif-ur-rehmanAdaptiveSpikeDeepclassifierSelforganizing2025,

title = {Adaptive SpikeDeep-classifier: Self-organizing and Self-Supervised Machine Learning Algorithm for Online Spike Sorting},

author = {Muhammad Saif-ur-Rehman and Omair Ali and Christian Klaes and Ioannis Iossifidis},

editor = {Elsevier},

url = {https://www.sciencedirect.com/science/article/pii/S0925231225020429},

doi = {10.1016/j.neucom.2025.131370},

issn = {0925-2312},

year  = {2025},

date = {2025-09-04},

urldate = {2025-09-04},

journal = {Neurocomputing},

pages = {131370},

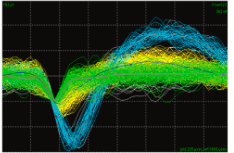
abstract = {Objective. Invasive brain-computer interface (BCI) research is progressing towards the realization of the motor skills rehabilitation of severely disabled patients in the real world. The size of invasive micro-electrode arrays and the selection of an efficient online spike sorting algorithm (performing spike sorting at run time) are two key factors that play pivotal roles in the successful decoding of the user’s intentions. The process of spike sorting includes the selection of channels that record the spike activity (SA) and determines the SA of different sources (neurons), on selected channels individually. The neural data recorded with dense micro-electrode arrays is time-varying and often contaminated with non-stationary noise. Unfortunately, current state-of-the-art spike sorting algorithms are incapable of handling the massively increasing amount of time-varying data resulting from the dense microelectrode arrays, which makes the spike sorting one of the fragile components of the online BCI decoding framework. Approach. This study proposed an adaptive and self-organized algorithm for online spike sorting, named as Adaptive SpikeDeep-Classifier (Ada-SpikeDeepClassifier). Our algorithm uses SpikeDeeptector for the channel selection, an adaptive background activity rejector (Ada-BAR) for discarding the background events, and an adaptive spike deep-classifier (Ada-SpikeDeepClassifier) for classifying the SA of different neural units. The process of spike sorting is accomplished by concatenating SpikeDeeptector, Ada-BAR and Ada-SpikeDeepclassifier. Results. The proposed algorithm is evaluated on two different categories of data: a human data-set recorded in our lab, and a publicly available simulated data-set to avoid subjective biases and labeling errors. The proposed Ada-SpikeDeepClassifier outperformed our previously published SpikeDeep-Classifier and eight conventional spike sorting algorithms and produce comparable results to state of the art deep learning based algorithms. Significance. To the best of our knowledge, the proposed algorithm is the first spike sorting algorithm that autonomously adapts to the shift in the distribution of noise and SA data and perform spike sorting without human interventions in various kinds of experimental settings. In addition, the proposed algorithm builds upon artificial neural networks, which makes it an ideal candidate for being embedded on neuromorphic chips that are also suitable for wearable invasive BCI.},

keywords = {BCI, Brain computer interface, Deep learning, Self organizing, Self-supervised machine learning, Spike Sorting},

pubstate = {published},

tppubtype = {article}

}
Tim Sziburis; Susanne Blex; Tobias Glasmachers; Ioannis Iossifidis
Hand Motion Catalog of Human Center-Out Transport Trajectories Measured Redundantly in 3D Task-Space Journal Article
In: vol. 12, no. 1, pp. 1293, 2025, ISSN: 2052-4463.
Abstract | Links | BibTeX | Tags: Biomedical engineering, Motor control, Physiology
@article{sziburisHandMotionCatalog2025,

title = {Hand Motion Catalog of Human Center-Out Transport Trajectories Measured Redundantly in 3D Task-Space},

author = {Tim Sziburis and Susanne Blex and Tobias Glasmachers and Ioannis Iossifidis},

editor = {Nature},

url = {https://www.nature.com/articles/s41597-025-05576-7},

doi = {10.1038/s41597-025-05576-7},

issn = {2052-4463},

year  = {2025},

date = {2025-07-24},

urldate = {2025-07-24},

volume = {12},

number = {1},

pages = {1293},

publisher = {Nature Publishing Group},

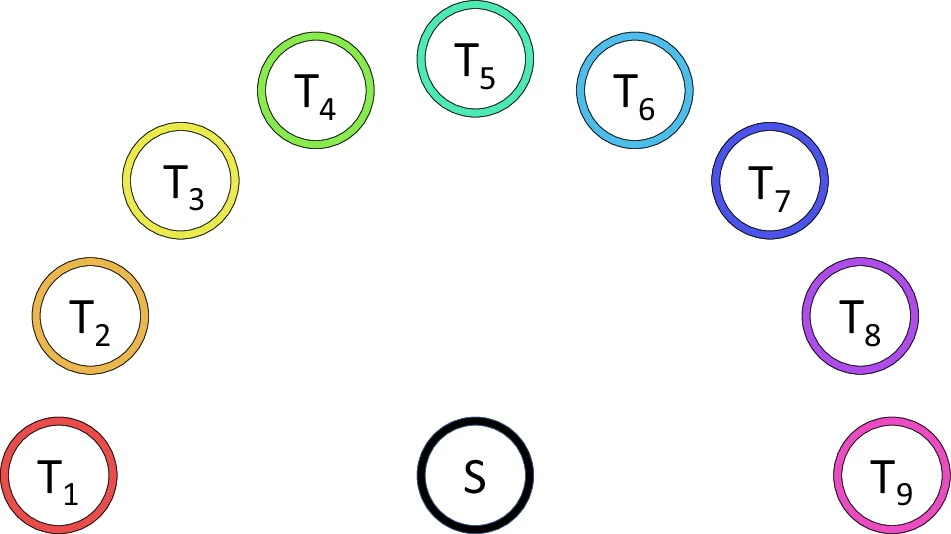
abstract = {Motion modeling and variability analysis bear the potential to identify movement pathology but require profound data. We introduce a systematic dataset of 3D center-out task-space trajectories of human hand transport movements in a standardized setting. This set-up is characterized by reproducibility, leading to reliable transferability to various locations. The transport tasks consist of grasping a cylindrical object from a unified start position and transporting it to one of nine target locations in unconstrained operational space. The measurement procedure is automatized to record ten trials per target location and participant. The dataset comprises 90 movement trajectories for each hand of 31 participants without known movement disorders (21 to 78 years), resulting in 5580 trials. In addition, handedness is determined using the EHI. Data are recorded redundantly and synchronously by an optical tracking system and a single IMU sensor. Unlike the stationary capturing system, the IMU can be considered a portable, low-cost, and energy-efficient alternative to be implemented on embedded systems, for example in medical evaluation scenarios.},

keywords = {Biomedical engineering, Motor control, Physiology},

pubstate = {published},

tppubtype = {article}

}
Aline Xavier Fidêncio; Felix Grün; Christian Klaes; Ioannis Iossifidis
Hybrid Brain-Computer Interface Using Error-Related Potential and Reinforcement Learning Journal Article
In: Frontiers in Human Neuroscience, vol. 19, 2025, ISSN: 1662-5161.
Abstract | Links | BibTeX | Tags: adaptive brain-computer interface, BCI, EEG, error-related potentials (ErrPs), Machine Learning, motor imagery (MI), reinforcement learning (RL)
@article{xavierfidencioHybridBraincomputerInterface2025,

title = {Hybrid Brain-Computer Interface Using Error-Related Potential and Reinforcement Learning},

author = {Aline Xavier Fidêncio and Felix Grün and Christian Klaes and Ioannis Iossifidis},

editor = {Frontiers},

url = {https://www.frontiersin.org/journals/human-neuroscience/articles/10.3389/fnhum.2025.1569411/full},

doi = {10.3389/fnhum.2025.1569411},

issn = {1662-5161},

year  = {2025},

date = {2025-06-04},

urldate = {2025-06-04},

journal = {Frontiers in Human Neuroscience},

volume = {19},

publisher = {Frontiers},

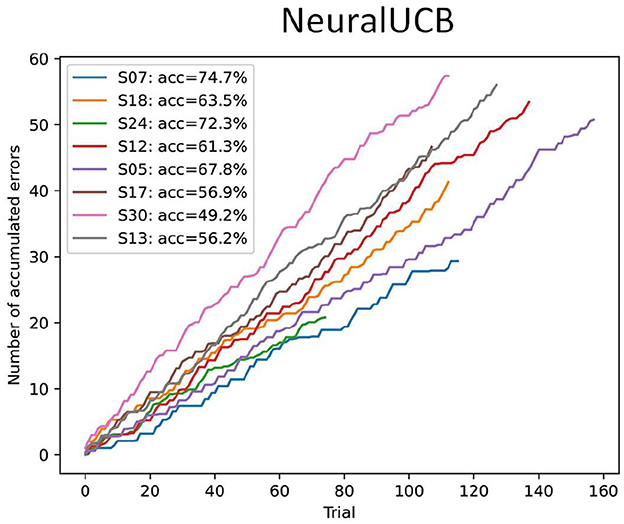
abstract = {Brain-computer interfaces (BCIs) offer alternative communication methods for individuals with motor disabilities, aiming to improve their quality of life through external device control. However, non-invasive BCIs using electroencephalography (EEG) often suffer from performance limitations due to non-stationarities arising from changes in mental state or device characteristics. Addressing these challenges motivates the development of adaptive systems capable of real-time adjustment. This study investigates a novel approach for creating an adaptive, error-related potential (ErrP)-based BCI using reinforcement learning (RL) to dynamically adapt to EEG signal variations. The framework was validated through experiments on a publicly available motor imagery dataset and a novel fast-paced protocol designed to enhance user engagement. Results showed that RL agents effectively learned control policies from user interactions, maintaining robust performance across datasets. However, findings from the game-based protocol revealed that fast-paced motor imagery tasks were ineffective for most participants, highlighting critical challenges in real-time BCI task design. Overall, the results demonstrate the potential of RL for enhancing BCI adaptability while identifying practical constraints in task complexity and user responsiveness.},

keywords = {adaptive brain-computer interface, BCI, EEG, error-related potentials (ErrPs), Machine Learning, motor imagery (MI), reinforcement learning (RL)},

pubstate = {published},

tppubtype = {article}

}
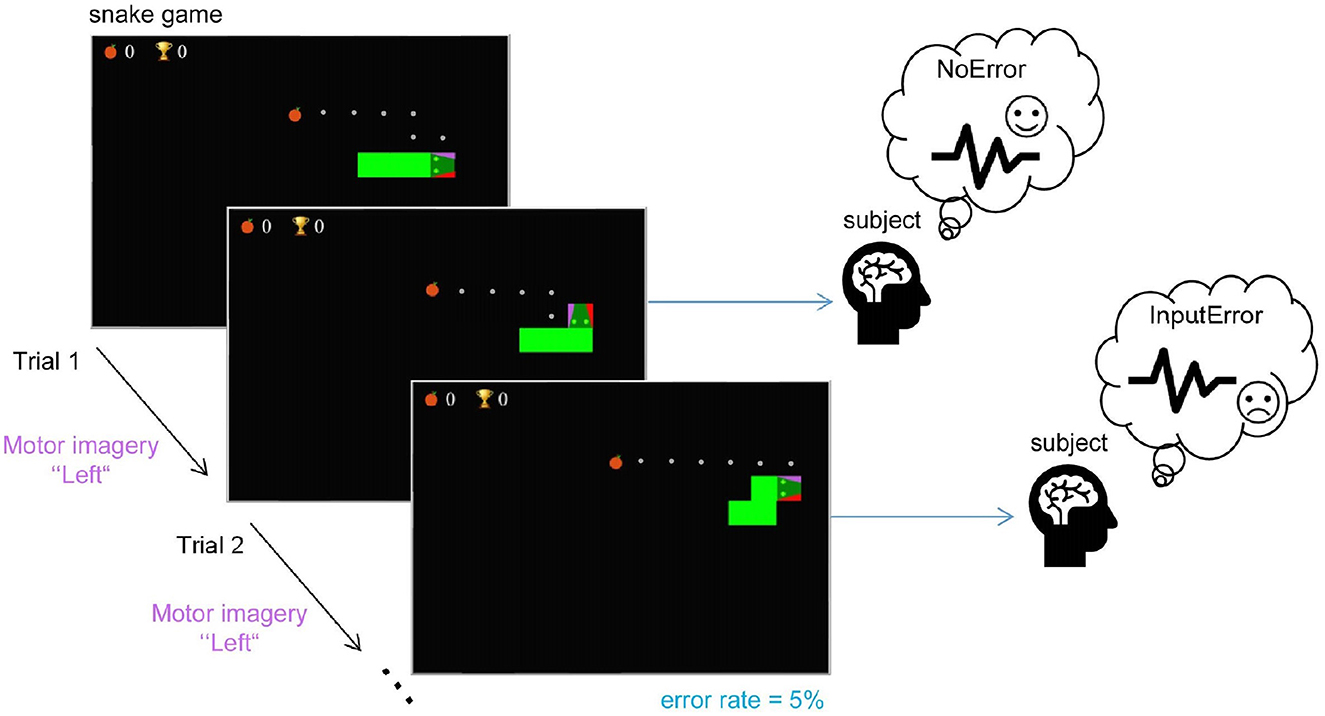
Aline Xavier Fidêncio; Felix Grün; Christian Klaes; Ioannis Iossifidis
Error-Related Potential Driven Reinforcement Learning for Adaptive Brain-Computer Interfaces Journal Article
In: Arxiv, 2025.
Abstract | Links | BibTeX | Tags: BCI, Computer Science - Human-Computer Interaction, Computer Science - Machine Learning, EEG, Quantitative Biology - Neurons and Cognition, Reinforcement learning
@article{fidencioErrorrelatedPotentialDriven2025,

title = {Error-Related Potential Driven Reinforcement Learning for Adaptive Brain-Computer Interfaces},

author = {Aline Xavier Fidêncio and Felix Grün and Christian Klaes and Ioannis Iossifidis},

url = {http://arxiv.org/abs/2502.18594},

doi = {10.48550/arXiv.2502.18594},

year  = {2025},

date = {2025-02-25},

urldate = {2025-02-25},

journal = {Arxiv},

abstract = {Brain-computer interfaces (BCIs) provide alternative communication methods for individuals with motor disabilities by allowing control and interaction with external devices. Non-invasive BCIs, especially those using electroencephalography (EEG), are practical and safe for various applications. However, their performance is often hindered by EEG non-stationarities, caused by changing mental states or device characteristics like electrode impedance. This challenge has spurred research into adaptive BCIs that can handle such variations. In recent years, interest has grown in using error-related potentials (ErrPs) to enhance BCI performance. ErrPs, neural responses to errors, can be detected non-invasively and have been integrated into different BCI paradigms to improve performance through error correction or adaptation. This research introduces a novel adaptive ErrP-based BCI approach using reinforcement learning (RL). We demonstrate the feasibility of an RL-driven adaptive framework incorporating ErrPs and motor imagery. Utilizing two RL agents, the framework adapts dynamically to EEG non-stationarities. Validation was conducted using a publicly available motor imagery dataset and a fast-paced game designed to boost user engagement. Results show the framework's promise, with RL agents learning control policies from user interactions and achieving robust performance across datasets. However, a critical insight from the game-based protocol revealed that motor imagery in a high-speed interaction paradigm was largely ineffective for participants, highlighting task design limitations in real-time BCI applications. These findings underscore the potential of RL for adaptive BCIs while pointing out practical constraints related to task complexity and user responsiveness.},

keywords = {BCI, Computer Science - Human-Computer Interaction, Computer Science - Machine Learning, EEG, Quantitative Biology - Neurons and Cognition, Reinforcement learning},

pubstate = {published},

tppubtype = {article}

}
2024
Tim Sziburis; Susanne Blex; Tobias Glasmachers; Ioannis Iossifidis
Deep-learning-based identification of individual motion characteristics from upper-limb trajectories towards disorder stage evaluation Inproceedings
In: Pons, Jose L.; Tornero, Jesus; Akay, Metin (Ed.): Converging Clinical and Engineering Research on Neurorehabilitation V - Proceedings of the 6th International Conference on Neurorehabilitation (ICNR2024), Springer International Publishing, La Granja, Spain, 2024.
BibTeX | Tags:
@inproceedings{icnr2024,

title = {Deep-learning-based identification of individual motion characteristics from upper-limb trajectories towards disorder stage evaluation},

author = {Tim Sziburis and Susanne Blex and Tobias Glasmachers and Ioannis Iossifidis},

editor = {Jose L. Pons and Jesus Tornero and Metin Akay},

year  = {2024},

date = {2024-11-30},

urldate = {2024-11-30},

booktitle = {Converging Clinical and Engineering Research on Neurorehabilitation V - Proceedings of the 6th International Conference on Neurorehabilitation (ICNR2024)},

publisher = {Springer International Publishing},

address = {La Granja, Spain},

series = {Biosystems and Biorobotics},

keywords = {},

pubstate = {published},

tppubtype = {inproceedings}

}
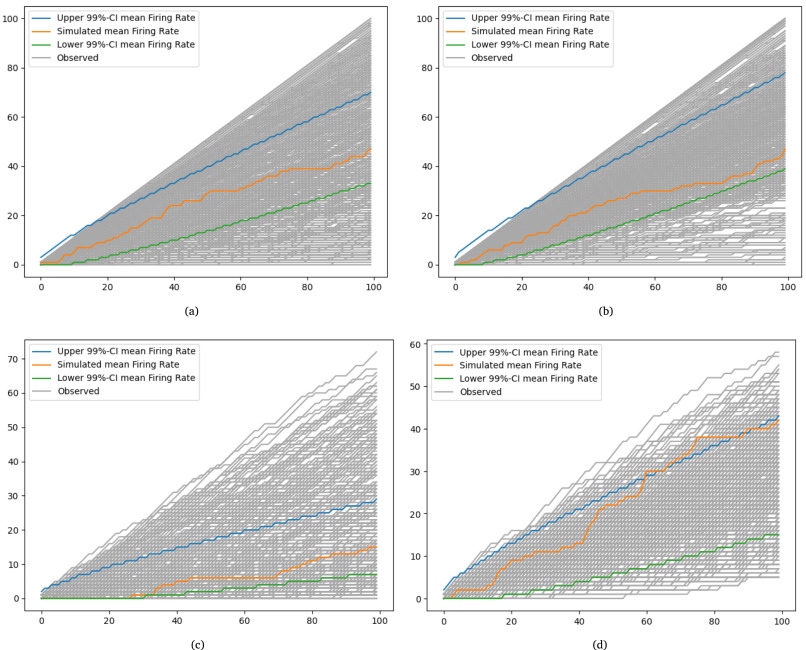
Stephan Johann Lehmler; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis
In: Neurocomputing, pp. 128473, 2024, ISSN: 0925-2312.
Abstract | Links | BibTeX | Tags: Artificial neural networks, Generalization, Memorization, Poisson process, Stochastic modeling
@article{lehmlerUnderstandingActivationPatterns2024,

title = {Understanding Activation Patterns in Artificial Neural Networks by Exploring Stochastic Processes: Discriminating Generalization from Memorization},

author = {Stephan Johann Lehmler and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis},

url = {https://www.sciencedirect.com/science/article/pii/S092523122401244X},

doi = {10.1016/j.neucom.2024.128473},

issn = {0925-2312},

year  = {2024},

date = {2024-09-19},

urldate = {2024-09-19},

journal = {Neurocomputing},

pages = {128473},

abstract = {To gain a deeper understanding of the behavior and learning dynamics of artificial neural networks, mathematical abstractions and models are valuable. They provide a simplified perspective and facilitate systematic investigations. In this paper, we propose to analyze dynamics of artificial neural activation using stochastic processes, which have not been utilized for this purpose thus far. Our approach involves modeling the activation patterns of nodes in artificial neural networks as stochastic processes. By focusing on the activation frequency, we can leverage techniques used in neuroscience to study neural spike trains. Specifically, we extract the activity of individual artificial neurons during a classification task and model their activation frequency. The underlying process model is an arrival process following a Poisson distribution.We examine the theoretical fit of the observed data generated by various artificial neural networks in image recognition tasks to the proposed model’s key assumptions. Through the stochastic process model, we derive measures describing activation patterns of each network. We analyze randomly initialized, generalizing, and memorizing networks, allowing us to identify consistent differences in learning methods across multiple architectures and training sets. We calculate features describing the distribution of Activation Rate and Fano Factor, which prove to be stable indicators of memorization during learning. These calculated features offer valuable insights into network behavior. The proposed model demonstrates promising results in describing activation patterns and could serve as a general framework for future investigations. It has potential applications in theoretical simulation studies as well as practical areas such as pruning or transfer learning.},

keywords = {Artificial neural networks, Generalization, Memorization, Poisson process, Stochastic modeling},

pubstate = {published},

tppubtype = {article}

}
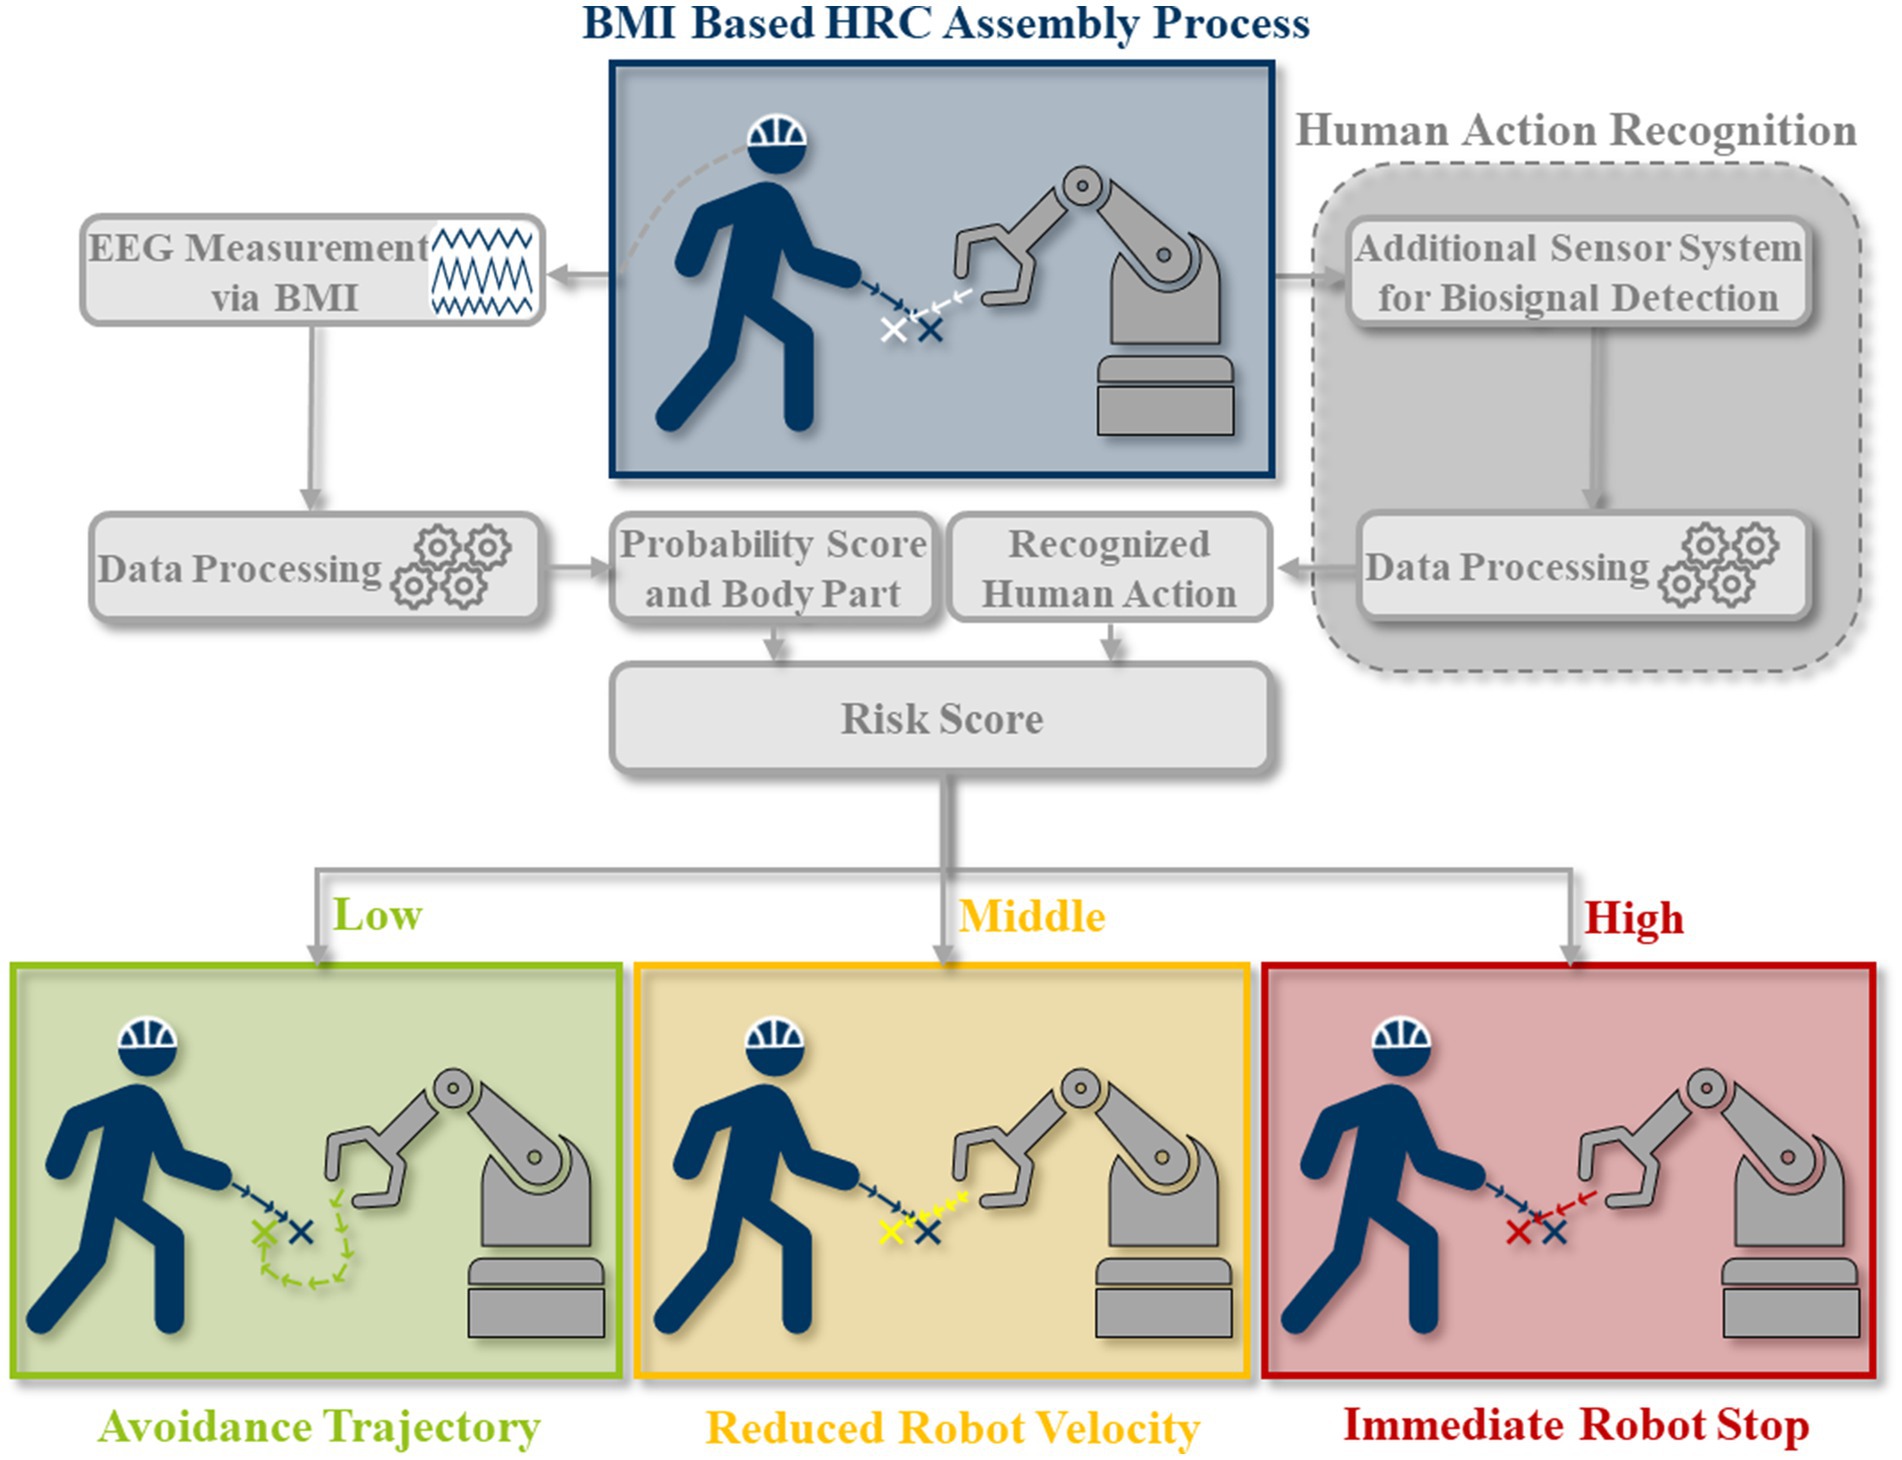
Artur Pilacinski; Lukas Christ; Marius Boshoff; Ioannis Iossifidis; Patrick Adler; Michael Miro; Bernd Kuhlenkötter; Christian Klaes
In: Frontiers in Neurorobotics, vol. 18, 2024, ISSN: 1662-5218.
Links | BibTeX | Tags: brain-machine interfaces, EEG, Human action recognition, Human-robot collaboration, Sensor Fusion
@article{pilacinskiHumanCollaborativeLoop2024b,

title = {Human in the Collaborative Loop: A Strategy for Integrating Human Activity Recognition and Non-Invasive Brain-Machine Interfaces to Control Collaborative Robots},

author = {Artur Pilacinski and Lukas Christ and Marius Boshoff and Ioannis Iossifidis and Patrick Adler and Michael Miro and Bernd Kuhlenkötter and Christian Klaes},

url = {https://www.frontiersin.org/journals/neurorobotics/articles/10.3389/fnbot.2024.1383089/full},

doi = {10.3389/fnbot.2024.1383089},

issn = {1662-5218},

year  = {2024},

date = {2024-09-18},

urldate = {2024-09-18},

journal = {Frontiers in Neurorobotics},

volume = {18},

publisher = {Frontiers},

keywords = {brain-machine interfaces, EEG, Human action recognition, Human-robot collaboration, Sensor Fusion},

pubstate = {published},

tppubtype = {article}

}
Aline Xavier Fidencio; Christian Klaes; Ioannis Iossifidis
Adaptive Brain-Computer Interfaces Based on Error-Related Potentials and Reinforcement Learning Inproceedings
In: BC24 : Computational Neuroscience & Neurotechnology Bernstein Conference 2024, BCCN Bernstein Network Computational Networkvphantom, 2024.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning
@inproceedings{AdaptiveBraincomputerInterfaces2024,

title = {Adaptive Brain-Computer Interfaces Based on Error-Related Potentials and Reinforcement Learning},

author = {Aline Xavier Fidencio and Christian Klaes and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC24/abstracts#/uuid/03d3dd16-4c50-43d8-b878-abcfa7857386},

year  = {2024},

date = {2024-09-18},

urldate = {2024-09-24},

booktitle = {BC24 : Computational Neuroscience & Neurotechnology Bernstein Conference 2024},

publisher = {BCCN Bernstein Network Computational Networkvphantom},

abstract = {Error-related potentials (ErrPs) represent the neural signature of error processing in the brain and numerous studies have demonstrated their reliable detection using non-invasive techniques such as electroencephalography (EEG). Over recent decades, the brain-computer interface (BCI) community has shown growing interest in leveraging these intrinsic feedback signals to enhance system performance. However, the effective use of ErrPs in a closed-loop setup crucially depends on accurate single-trial detection, which is typically achieved using a subject-specific classifier (or decoder) trained on samples recorded during extensive calibration sessions before the BCI system can be deployed. In our research, we explore the potential of simulated EEG data for training a truly generic ErrP classifier. Utilizing the SEREEGA simulator, we demonstrate that EEG data can be generated in a cost-effective manner, allowing for controlled and systematic variations in data distribution to accommodate uncertainties in ErrP generation. A classifier trained solely on the generated data exhibits promising generalization capabilities across different datasets and performs comparably to a leave-one-subject-out approach trained on real data (Xavier Fidêncio et al., 2024). In our experiments, we deliberately provoked ErrPs when the BCI misinterpreted the user's intention, resulting in incorrect actions. Subjects engaged in a game controlled via keyboard and/or motor imagery (imagining hand movements), with EEG data recorded using various EEG systems for comparison. Considering the challenges in obtaining clear ErrP signals for all subjects and the limitations identified in existing literature (Xavier Fidêncio et al., 2022), we hypothesize whether a measurable error signal is consistently generated at the scalp level when subjects encounter erroneous conditions, and how this influences closed-loop setups that incorporate ErrPs for improved BCI performance. To address these questions, we assess the effects of the occurrence-to-detection ratio of ErrPs in the classification pipeline using simulated data and explore the impact of error misclassification rates in an ErrP-based learning framework, which employs reinforcement learning to enhance BCI performance.},

keywords = {BCI, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Felix Grün; Ioannis Iossifidis
Controversial Opinions on Model Based and Model Free Reinforcement Learning in the Brain Inproceedings
In: BCCN Bernstein Network Computational Networkvphantom, 2024.
Abstract | Links | BibTeX | Tags: Machine Learning, Reinforcement learning
@inproceedings{ControversialOpinionsModel2024,

title = {Controversial Opinions on Model Based and Model Free Reinforcement Learning in the Brain},

author = {Felix Grün and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC24/abstracts#/uuid/18e92e07-e4b1-43af-b2ac-ea282f4e81e7},

year  = {2024},

date = {2024-09-18},

urldate = {2024-09-24},

publisher = {BCCN Bernstein Network Computational Networkvphantom},

abstract = {Dopaminergic Reward Prediction Errors (RPEs) are a key motivation and inspiration for model free, temporal difference reinforcement learning methods. Originally, the correlation of RPEs with model free temporal difference errors was seen as a strong indicator for model free reinforcement learning in brains. The standard view was that model free learning is the norm and more computationally expensive model based decision-making is only used when it leads to outcomes that are good enough to justify the additional effort. Nowadays, the landscape of opinions, models and experimental evidence, both electrophysiological and behavioral, paints a more complex picture, including but not limited to mechanisms of arbitration between the two systems. Model based learning or hybrid models better capture experimental behavioral data, and model based signatures are found in RPEs that were previously thought to be model free or hybrid [1]. The evidence for clearly model free learning is scarce [2]. On the other hand, multiple approaches show how model based behavior and RPEs can be produced with fundamentally model free reinforcement learning methods [3, 4, 5]. We point out findings that seem to contradict each other, others that complement each other, speculate which ideas are compatible with each other and give our opinions on ways forward, towards understanding if and how model based and model free learning from rewards coexist and interact in the brain.},

keywords = {Machine Learning, Reinforcement learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Ioannis Iossifidis
Decoding Upper Limb Movements Inproceedings
In: BCCN Bernstein Network Computational Networkvphantom, 2024.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning, Muscle activity
@inproceedings{DecodingUpperLimb2024,

title = {Decoding Upper Limb Movements},

author = {Marie Dominique Schmidt and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC24/abstracts#/uuid/4725140f-ce7c-4ac5-b694-c627ceeb8d98},

doi = {DOI: 10.12751/nncn.bc2024.257},

year  = {2024},

date = {2024-09-18},

urldate = {2024-09-18},

publisher = {BCCN Bernstein Network Computational Networkvphantom},

abstract = {The upper limbs are essential for performing everyday tasks that require a wide range of motion and precise coordination. Planning and timing are crucial to achieve coordinated movement. Sensory information about the target and current body state is critical, as is the integration of prior experience represented by prelearned inverse dynamics that generate the associated muscle activity. We propose a generative model that uses a recurrent neural network to predict upper limb muscle activity during various simple and complex everyday movements. By identifying movement primitives within the signal, our model enables the decomposition of these movements into a fundamental set, facilitating the reconstruction of muscle activity patterns. Our approach has implications for the fundamental understanding of movement control and the rehabilitation of neuromuscular disorders with myoelectric prosthetics and functional electrical stimulation.},

keywords = {BCI, Machine Learning, Muscle activity},

pubstate = {published},

tppubtype = {inproceedings}

}
Stephan Johann Lehmler; Ioannis Iossifidis
In: BC24 : Computational Neuroscience & Neurotechnology Bernstein Conference 2024, BCCN Bernstein Network Computational Networkvphantom, 2024.
Abstract | Links | BibTeX | Tags: Machine Learning
@inproceedings{StochasticProcessModel2024,

title = {Stochastic Process Model Derived Indicators of Overfitting for Deep Architectures: Applicability to Small Sample Recalibration of sEMG Decoders},

author = {Stephan Johann Lehmler and Ioannis Iossifidis},

url = {https://abstracts.g-node.org/conference/BC24/abstracts#/uuid/72f03ff1-61dc-443c-92c2-b623d672ce15},

year  = {2024},

date = {2024-09-18},

urldate = {2024-09-24},

booktitle = {BC24 : Computational Neuroscience & Neurotechnology Bernstein Conference 2024},

publisher = {BCCN Bernstein Network Computational Networkvphantom},

abstract = {Our recent work presents a stochastic process model of the activations within an ANN and shows a promising indicator to distinguish memorizing from generalizing ANNs. The average λ, or mean firing rate (MFR), of a hidden layer, shows stable differences between memorizing and generalizing networks, comparatively independent of the underlying data used for evaluation. We first show the performance of this indicator during training on benchmark computer vision datasets such as MNIST and CIFAR-10. In a second step, we extend the work to the real-life use case of calibrating a pre-trained model to a new user. We focus on decoding surface electromyographic (sEMG) signals, which are highly variable within and between users, and therefore necessitate frequent user calibration. Especially in situations when user calibration has to only rely on a small number of samples, degradation in performance overtime due to memorization and overfitting is a not unlikely outcome. In those cases, traditional regularization methods that function by observing the performance on a validation set, such as early stopping, don’t necessarily work, because they are evaluated on data from the same subject and set of movements, which features are being memorized. Our new indicators of memorization could help as stable indicators for model performance and give live insights during model calibration when more samples from the new users would be necessary. We evaluate the usefulness of the MFR-indicator for identifying the moment a pre-trained sEMG decoder starts to memorize given inputs},

keywords = {Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
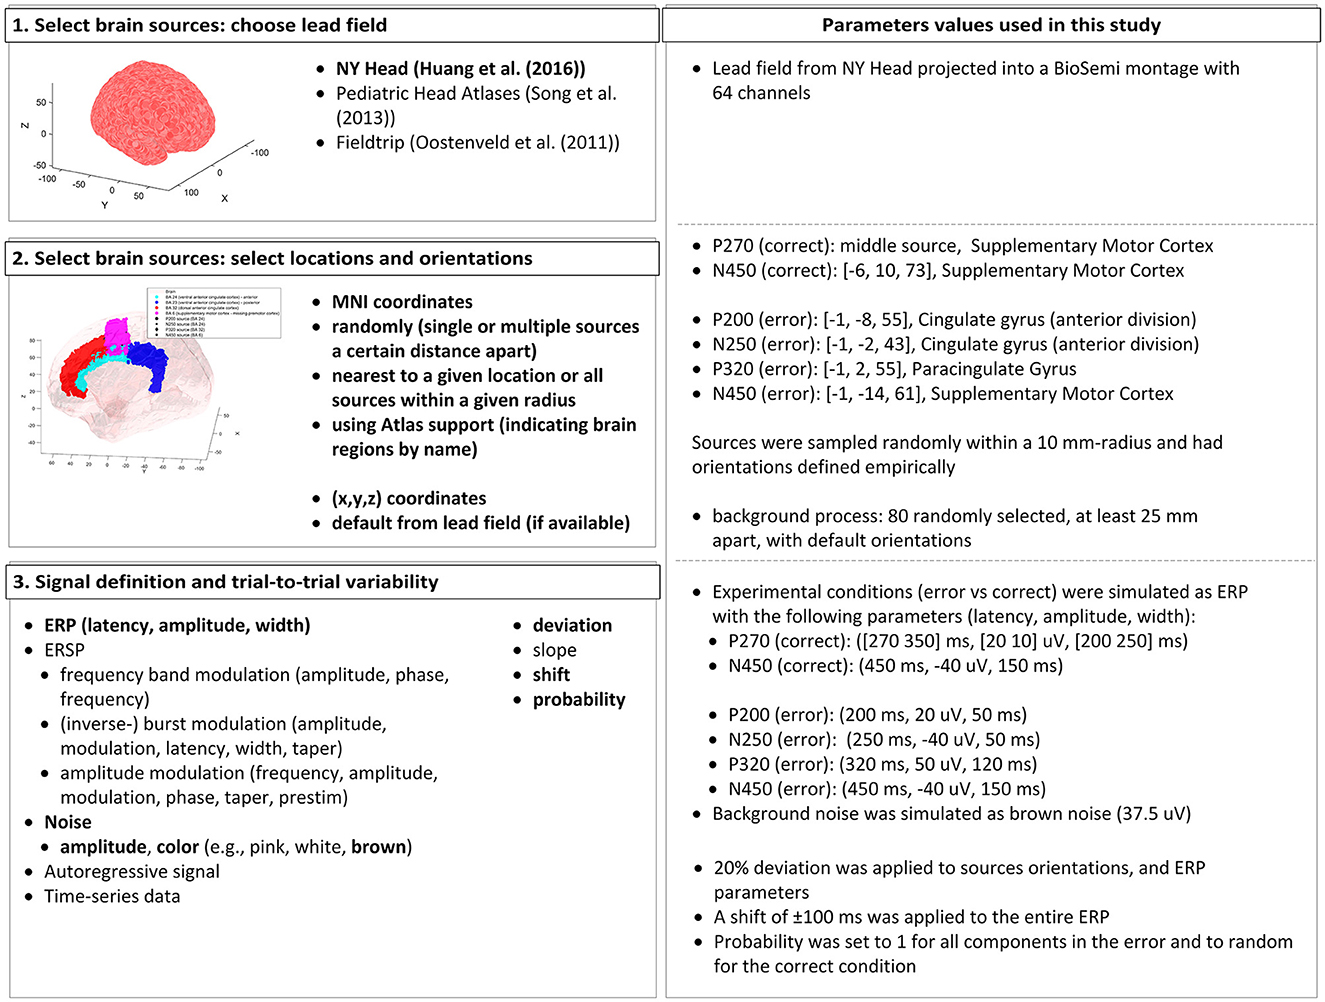
Aline Xavier Fidêncio; Christian Klaes; Ioannis Iossifidis
A Generic Error-Related Potential Classifier Based on Simulated Subjects Journal Article
In: Frontiers in Human Neuroscience, vol. 18, pp. 1390714, 2024, ISSN: 1662-5161.
Abstract | Links | BibTeX | Tags: adaptive brain-machine (computer) interface, BCI, EEG, Error-related potential (ErrP), ErrP classifier, Generic decoder, Machine Learning, SEREEGA, Simulation
@article{xavierfidencioGenericErrorrelatedPotential2024b,

title = {A Generic Error-Related Potential Classifier Based on Simulated Subjects},

author = {Aline Xavier Fidêncio and Christian Klaes and Ioannis Iossifidis},

editor = {Frontiers Media SA},

url = {https://www.frontiersin.org/journals/human-neuroscience/articles/10.3389/fnhum.2024.1390714/full},

doi = {10.3389/fnhum.2024.1390714},

issn = {1662-5161},

year  = {2024},

date = {2024-07-19},

urldate = {2024-07-19},

journal = {Frontiers in Human Neuroscience},

volume = {18},

pages = {1390714},

publisher = {Frontiers},

abstract = {$<$p$>$Error-related potentials (ErrPs) are brain signals known to be generated as a reaction to erroneous events. Several works have shown that not only self-made errors but also mistakes generated by external agents can elicit such event-related potentials. The possibility of reliably measuring ErrPs through non-invasive techniques has increased the interest in the brain-computer interface (BCI) community in using such signals to improve performance, for example, by performing error correction. Extensive calibration sessions are typically necessary to gather sufficient trials for training subject-specific ErrP classifiers. This procedure is not only time-consuming but also boresome for participants. In this paper, we explore the effectiveness of ErrPs in closed-loop systems, emphasizing their dependency on precise single-trial classification. To guarantee the presence of an ErrPs signal in the data we employ and to ensure that the parameters defining ErrPs are systematically varied, we utilize the open-source toolbox SEREEGA for data simulation. We generated training instances and evaluated the performance of the generic classifier on both simulated and real-world datasets, proposing a promising alternative to conventional calibration techniques. Results show that a generic support vector machine classifier reaches balanced accuracies of 72.9%, 62.7%, 71.0%, and 70.8% on each validation dataset. While performing similarly to a leave-one-subject-out approach for error class detection, the proposed classifier shows promising generalization across different datasets and subjects without further adaptation. Moreover, by utilizing SEREEGA, we can systematically adjust parameters to accommodate the variability in the ErrP, facilitating the systematic validation of closed-loop setups. Furthermore, our objective is to develop a universal ErrP classifier that captures the signal's variability, enabling it to determine the presence or absence of an ErrP in real EEG data.$<$/p$>$},

keywords = {adaptive brain-machine (computer) interface, BCI, EEG, Error-related potential (ErrP), ErrP classifier, Generic decoder, Machine Learning, SEREEGA, Simulation},

pubstate = {published},

tppubtype = {article}

}
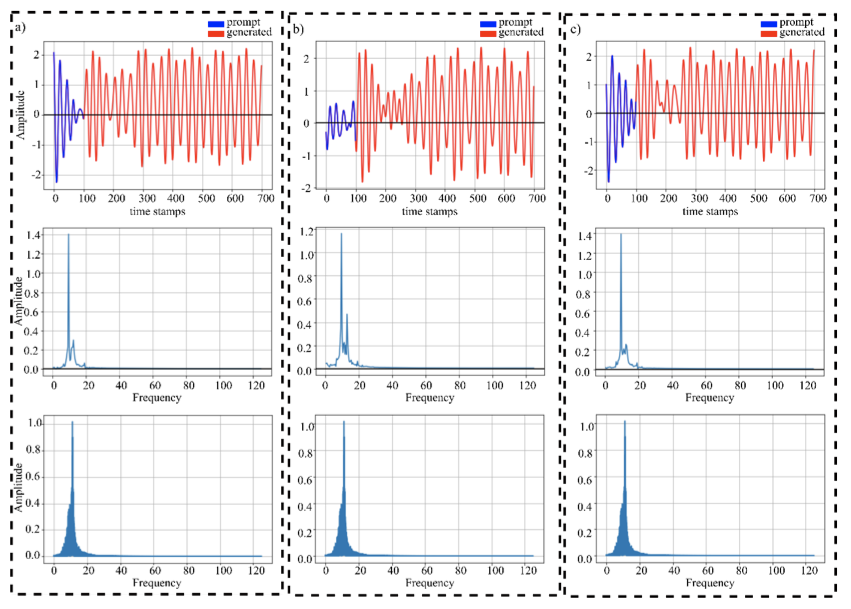
Omair Ali; Muhammad Saif-ur-Rehman; Marita Metzler; Tobias Glasmachers; Ioannis Iossifidis; Christian Klaes
GET: A Generative EEG Transformer for Continuous Context-Based Neural Signals Journal Article
In: arXiv:2406.03115 [q-bio], 2024.
Abstract | Links | BibTeX | Tags: BCI, EEG, Machine Learning, Quantitative Biology - Neurons and Cognition
@article{aliGETGenerativeEEG2024,

title = {GET: A Generative EEG Transformer for Continuous Context-Based Neural Signals},

author = {Omair Ali and Muhammad Saif-ur-Rehman and Marita Metzler and Tobias Glasmachers and Ioannis Iossifidis and Christian Klaes},

url = {http://arxiv.org/abs/2406.03115},

doi = {10.48550/arXiv.2406.03115},

year  = {2024},

date = {2024-06-09},

urldate = {2024-06-09},

journal = {arXiv:2406.03115 [q-bio]},

abstract = {Generating continuous electroencephalography (EEG) signals through advanced artificial neural networks presents a novel opportunity to enhance brain-computer interface (BCI) technology. This capability has the potential to significantly enhance applications ranging from simulating dynamic brain activity and data augmentation to improving real-time epilepsy detection and BCI inference. By harnessing generative transformer neural networks, specifically designed for EEG signal generation, we can revolutionize the interpretation and interaction with neural data. Generative AI has demonstrated significant success across various domains, from natural language processing (NLP) and computer vision to content creation in visual arts and music. It distinguishes itself by using large-scale datasets to construct context windows during pre-training, a technique that has proven particularly effective in NLP, where models are fine-tuned for specific downstream tasks after extensive foundational training. However, the application of generative AI in the field of BCIs, particularly through the development of continuous, context-rich neural signal generators, has been limited. To address this, we introduce the Generative EEG Transformer (GET), a model leveraging transformer architecture tailored for EEG data. The GET model is pre-trained on diverse EEG datasets, including motor imagery and alpha wave datasets, enabling it to produce high-fidelity neural signals that maintain contextual integrity. Our empirical findings indicate that GET not only faithfully reproduces the frequency spectrum of the training data and input prompts but also robustly generates continuous neural signals. By adopting the successful training strategies of the NLP domain for BCIs, the GET sets a new standard for the development and application of neural signal generation technologies.},

keywords = {BCI, EEG, Machine Learning, Quantitative Biology - Neurons and Cognition},

pubstate = {published},

tppubtype = {article}

}
2023
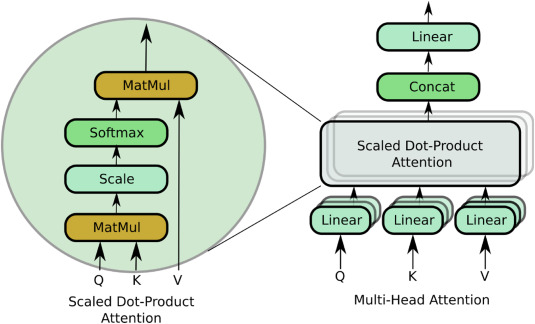
Omair Ali; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis; Christian Klaes
ConTraNet: A Hybrid Network for Improving the Classification of EEG and EMG Signals with Limited Training Data Journal Article
In: Computers in Biology and Medicine, pp. 107649, 2023, ISSN: 0010-4825.
Abstract | Links | BibTeX | Tags: Brain computer interface, Deep learning, EEG decoding, EMG decoding, Machine Learning
@article{aliConTraNetHybridNetwork2023,

title = {ConTraNet: A Hybrid Network for Improving the Classification of EEG and EMG Signals with Limited Training Data},

author = {Omair Ali and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis and Christian Klaes},

url = {https://www.sciencedirect.com/science/article/pii/S0010482523011149},

doi = {10.1016/j.compbiomed.2023.107649},

issn = {0010-4825},

year  = {2023},

date = {2023-11-02},

urldate = {2023-11-02},

journal = {Computers in Biology and Medicine},

pages = {107649},

abstract = {Objective Bio-Signals such as electroencephalography (EEG) and electromyography (EMG) are widely used for the rehabilitation of physically disabled people and for the characterization of cognitive impairments. Successful decoding of these bio-signals is however non-trivial because of the time-varying and non-stationary characteristics. Furthermore, existence of short- and long-range dependencies in these time-series signal makes the decoding even more challenging. State-of-the-art studies proposed Convolutional Neural Networks (CNNs) based architectures for the classification of these bio-signals, which are proven useful to learn spatial representations. However, CNNs because of the fixed size convolutional kernels and shared weights pay only uniform attention and are also suboptimal in learning short-long term dependencies, simultaneously, which could be pivotal in decoding EEG and EMG signals. Therefore, it is important to address these limitations of CNNs. To learn short- and long-range dependencies simultaneously and to pay more attention to more relevant part of the input signal, Transformer neural network-based architectures can play a significant role. Nonetheless, it requires a large corpus of training data. However, EEG and EMG decoding studies produce limited amount of the data. Therefore, using standalone transformers neural networks produce ordinary results. In this study, we ask a question whether we can fix the limitations of CNN and transformer neural networks and provide a robust and generalized model that can simultaneously learn spatial patterns, long-short term dependencies, pay variable amount of attention to time-varying non-stationary input signal with limited training data. Approach In this work, we introduce a novel single hybrid model called ConTraNet, which is based on CNN and Transformer architectures that contains the strengths of both CNN and Transformer neural networks. ConTraNet uses a CNN block to introduce inductive bias in the model and learn local dependencies, whereas the Transformer block uses the self-attention mechanism to learn the short- and long-range or global dependencies in the signal and learn to pay different attention to different parts of the signals. Main results We evaluated and compared the ConTraNet with state-of-the-art methods on four publicly available datasets (BCI Competition IV dataset 2b, Physionet MI-EEG dataset, Mendeley sEMG dataset, Mendeley sEMG V1 dataset) which belong to EEG-HMI and EMG-HMI paradigms. ConTraNet outperformed its counterparts in all the different category tasks (2-class, 3-class, 4-class, 7-class, and 10-class decoding tasks). Significance With limited training data ConTraNet significantly improves classification performance on four publicly available datasets for 2, 3, 4, 7, and 10-classes compared to its counterparts.},

keywords = {Brain computer interface, Deep learning, EEG decoding, EMG decoding, Machine Learning},

pubstate = {published},

tppubtype = {article}

}
Felix Grün; Ioannis Iossifidis
Investigation of the Interplay of Model-Based and Model-Free Learning Using Reinforcement Learning Inproceedings
In: BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2023.
@inproceedings{grunInvestigationInterplayModelBased2023,

title = {Investigation of the Interplay of Model-Based and Model-Free Learning Using Reinforcement Learning},

author = {Felix Grün and Ioannis Iossifidis},

year  = {2023},

date = {2023-09-15},

booktitle = {BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

abstract = {The reward prediction error hypothesis of dopamine in the brain states that activity of dopaminergic neurons in certain brain regions correlates with the reward prediction error that corresponds to the temporal difference error, often used as a learning signal in model free reinforcement learning (RL). This suggests that some form of reinforcement learning is used in animal and human brains when learning a task. On the other hand, it is clear that humans are capable of building an internal model of a task, or environment, and using it for planning, especially in sequential tasks. In RL, these two learning approaches, model-driven and reward-driven, are known as model based and model-free RL approaches. Both systems were previously thought to exist in parallel, with some higher process choosing which to use. A decade ago, research suggested both could be used concurrently, with some subject-specific weight assigned to each [1]. Still, the prevalent belief appeared to be that model-free learning is the default mechanism used, replaced or assisted by model-based planning only when the task demands it, i.e. higher rewards justify the additional cognitive effort. Recently, Feher da Silva et al. [2] questioned this belief, presenting data and analyses that indicate model-based learning may be used on its own and can even be computationally more efficient. We take a RL perspective, consider different ways to combine model-based and model-free approaches for modeling and for performance, and discuss how to further study this interplay in human behavioral experiments.},

keywords = {},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Ioannis Iossifidis
The Link between Muscle Activity and Upper Limb Kinematics Inproceedings
In: BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2023.
@inproceedings{schmidtLinkMuscleActivity2023,

title = {The Link between Muscle Activity and Upper Limb Kinematics},

author = {Marie Dominique Schmidt and Ioannis Iossifidis},

year  = {2023},

date = {2023-09-15},

booktitle = {BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

abstract = {The upper limbs are crucial in performing daily tasks that require strength, a wide range of motion, and precision. To achieve coordinated motion, planning and timing are critical. Sensory information about the target and the current body state is essential, as well as integrating past experiences, represented by pre-learned inverse dynamics that generate associated muscle activity. We propose a generative model that predicts upper limb muscle activity from a variety of simple and complex everyday motions by means of a recurrent neural network. The model shows promising results, with a good fit for different subjects and abstracts well for new motions. We handle the high inter-subject variation in muscle activity using a transfer learning approach, resulting in a good fit for new subjects. Our approach has implications for fundamental movement control understanding and the rehabilitation of neuromuscular diseases using myoelectric prostheses and functional electrical stimulation. Our model can efficiently predict both muscle activity and motion trajectory, which can assist in developing more effective rehabilitation techniques.},

keywords = {},

pubstate = {published},

tppubtype = {inproceedings}

}
Tim Sziburis; Susanne Blex; Ioannis Iossifidis
Variability Study of Human Hand Motion during 3D Center-out Tasks Captured for the Diagnosis of Movement Disorders Inproceedings
In: BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2023.
@inproceedings{sziburisVariabilityStudyHuman2023,

title = {Variability Study of Human Hand Motion during 3D Center-out Tasks Captured for the Diagnosis of Movement Disorders},

author = {Tim Sziburis and Susanne Blex and Ioannis Iossifidis},

year  = {2023},

date = {2023-09-15},

booktitle = {BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

abstract = {Variability analysis bears the potential to differentiate between healthy and pathological human movements [1]. Our study is conducted in the context of developing a portable glove for the diagnosis of movement disorders. This proposal has methodical as well as technical requirements. Generally, the identification of movement disorders via an analysis of motion data needs to be confirmed within the given setup. Typically, rhythmic movements like gait or posture control are examined for their variability, but here, the characteristic pathological traits of arm movement like tremors are under observation. In addition, the usability of a portable sensor instead of a stationary tracking system has to be validated. In this part of the project, human motion data are recorded redundantly by both an optical tracking system and an IMU. In our setup, a small cylinder is transported in three-dimensional space from a unified start position to one of nine target positions, which are equidistantly aligned on a semicircle. 10 trials are performed per target and hand, resulting in 180 trials per participant in total. 31 participants (11 female and 20 male) without known movement disorders, aged between 21 and 78 years, took part in the study. In addition, the 10-item EHI is used. The purpose of the analysis is to compare different variability measures to uncover differences between trials (intra-subject variability) and participants (inter-subject variability), especially in terms of age and handedness effects. Particularly, a novel variability measure is introduced which makes use of the characteristic planarity of the examined hand paths [2]. For this, the angle of the plane which best fits the travel phase of the trajectory is determined. In addition to neurological motivation, the advantage of this measure is that it allows the comparison of trials of different time spans and to different target directions without depending on trajectory warping. In the future, measurements of the same experimental setup with patients experiencing movement disorders are planned. For the subsequent pathological analysis, this study provides a basis in terms of methodological considerations and ground truth data of healthy participants. In parallel, the captured motion data are modelled utilizing dynamical systems (extended attractor dynamics approach). For this approach, the recorded and modelled data can be compared by the variability measures examined in this study.},

keywords = {},

pubstate = {published},

tppubtype = {inproceedings}

}
Aline Xavier Fidencio; Christian Klaes; Ioannis Iossifidis
Exploring Error-related Potentials in Adaptive Brain-Machine Interfaces: Challenges and Investigation of Occurrence and Detection Ratios Inproceedings
In: BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2023.
@inproceedings{xavierfidencioExploringErrorrelatedPotentials2023,

title = {Exploring Error-related Potentials in Adaptive Brain-Machine Interfaces: Challenges and Investigation of Occurrence and Detection Ratios},

author = {Aline Xavier Fidencio and Christian Klaes and Ioannis Iossifidis},

year  = {2023},

date = {2023-09-15},

booktitle = {BC23 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

abstract = {Non-invasive techniques like EEG can record error-related potentials (ErrPs), neural signals associated with error processing and awareness. ErrPs are generated in response to self-made and external errors, including those produced by the BMI. Since ErrPs are implicitly elicited and don’t add extra workload for the subject, they serve as a natural and intrinsic feedback source for developing adaptive BMIs. In our study, we assess the occurrence of interaction ErrPs in an adaptive BMI that combines ErrPs and reinforcement learning. We intentionally provoke ErrPs when the BMI misinterprets the user’s intention and performs an incorrect action. Subjects participated in a game controlled by a keyboard and/or motor imagery (imagining hand movements), and EEG data were recorded using an eight-electrode gel-based EEG system. Results reveal that obtaining a distinct ErrPs signal for each subject is more challenging than anticipated. Current practices report the ErrP in terms of over all subjects and trials difference grand average (error minus correct). This approach has, however, the limitation of masking the inter-trial and subject variability, which are relevant for the online single-trial detection of such signals. Moreover, the reported ErrPs waveshape exhibit differences in terms of components observed, as well as their respective latencies, even when very similar tasks are used. Consequently, we conducted additional individualized data analysis to gain deeper insights into the single-trial nature of the ErrPs. As a result, we determined the need for a better understanding and further investigation of how effectively the ErrPs waveforms generalize across subjects, tasks, experimental protocols, and feedback modalities. Given the challenges in obtaining a clear signal for all subjects and the limitations found in existing literature (Xavier Fidêncio et al., 2022), we hypothesize whether an error signal measurable at the scalp level is consistently generated when subjects encounter erroneous conditions. To address this question, we will assess the occurrence-to-detection ratio of ErrPs using invasive and non-invasive recording techniques, examining how uncertainties regarding error generation in the brain impact the learning pipeline.},

keywords = {},

pubstate = {published},

tppubtype = {inproceedings}

}
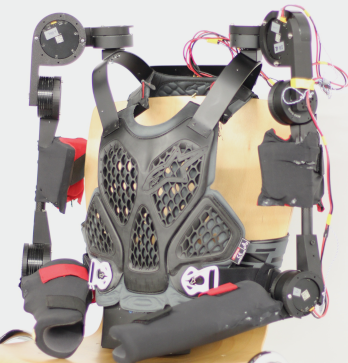
Muhammad Ayaz Hussain; Ioannis Iossifidis
Advancements in Upper Body Exoskeleton: Implementing Active Gravity Compensation with a Feedforward Controller Journal Article
In: arXiv:2309.04698 [cs.RO], 2023.
Abstract | Links | BibTeX | Tags: Computer Science - Artificial Intelligence, Computer Science - Information Theory, Computer Science - Machine Learning, I.2.6, I.2.8, Quantitative Biology - Neurons and Cognition
@article{ayazhussainAdvancementsUpperBody2023,

title = {Advancements in Upper Body Exoskeleton: Implementing Active Gravity Compensation with a Feedforward Controller},

author = {Muhammad Ayaz Hussain and Ioannis Iossifidis},

url = {https://doi.org/10.48550/arXiv.2309.04698},

doi = {10.48550/arXiv.2309.04698},

year  = {2023},

date = {2023-09-09},

urldate = {2023-09-09},

journal = {arXiv:2309.04698 [cs.RO]},

abstract = {In this study, we present a feedforward control system designed for active gravity compensation on an upper body exoskeleton. The system utilizes only positional data from internal motor sensors to calculate torque, employing analytical control equations based on Newton-Euler Inverse Dynamics. Compared to feedback control systems, the feedforward approach offers several advantages. It eliminates the need for external torque sensors, resulting in reduced hardware complexity and weight. Moreover, the feedforward control exhibits a more proactive response, leading to enhanced performance. The exoskeleton used in the experiments is lightweight and comprises 4 Degrees of Freedom, closely mimicking human upper body kinematics and three-dimensional range of motion. We conducted tests on both hardware and simulations of the exoskeleton, demonstrating stable performance. The system maintained its position over an extended period, exhibiting minimal friction and avoiding undesired slewing.},

keywords = {Computer Science - Artificial Intelligence, Computer Science - Information Theory, Computer Science - Machine Learning, I.2.6, I.2.8, Quantitative Biology - Neurons and Cognition},

pubstate = {published},

tppubtype = {article}

}
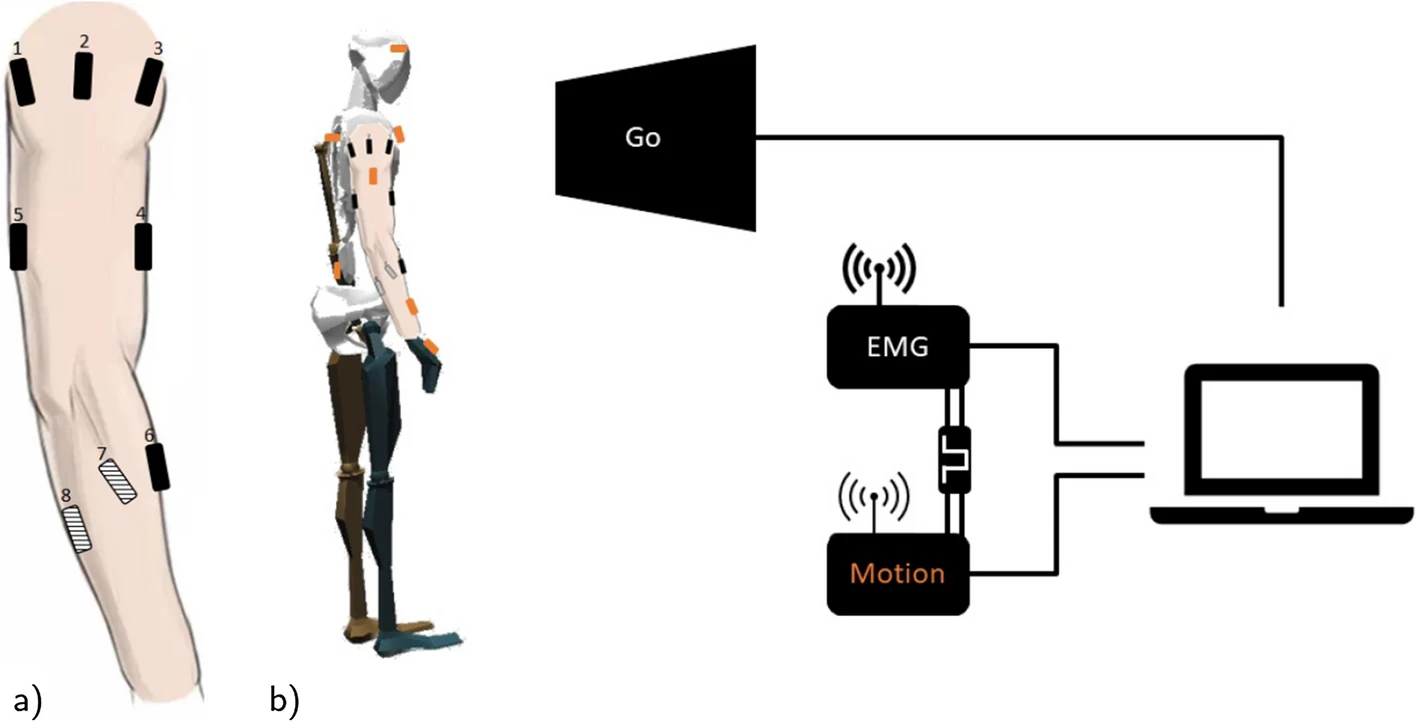
Marie D. Schmidt; Tobias Glasmachers; Ioannis Iossifidis
The Concepts of Muscle Activity Generation Driven by Upper Limb Kinematics Journal Article
In: BioMedical Engineering OnLine, vol. 22, no. 1, pp. 63, 2023, ISSN: 1475-925X.
Abstract | Links | BibTeX | Tags: Artificial generated signal, BCI, Electromyography (EMG), Generative model, Inertial measurement unit (IMU), Machine Learning, Motion parameters, Muscle activity, Neural networks, transfer learning, Voluntary movement
@article{schmidtConceptsMuscleActivity2023,

title = {The Concepts of Muscle Activity Generation Driven by Upper Limb Kinematics},

author = {Marie D. Schmidt and Tobias Glasmachers and Ioannis Iossifidis},

url = {https://doi.org/10.1186/s12938-023-01116-9},

doi = {10.1186/s12938-023-01116-9},

issn = {1475-925X},

year  = {2023},

date = {2023-06-24},

urldate = {2023-06-24},

journal = {BioMedical Engineering OnLine},

volume = {22},

number = {1},

pages = {63},

abstract = {The underlying motivation of this work is to demonstrate that artificial muscle activity of known and unknown motion can be generated based on motion parameters, such as angular position, acceleration, and velocity of each joint (or the end-effector instead), which are similarly represented in our brains. This model is motivated by the known motion planning process in the central nervous system. That process incorporates the current body state from sensory systems and previous experiences, which might be represented as pre-learned inverse dynamics that generate associated muscle activity.},

keywords = {Artificial generated signal, BCI, Electromyography (EMG), Generative model, Inertial measurement unit (IMU), Machine Learning, Motion parameters, Muscle activity, Neural networks, transfer learning, Voluntary movement},

pubstate = {published},

tppubtype = {article}

}
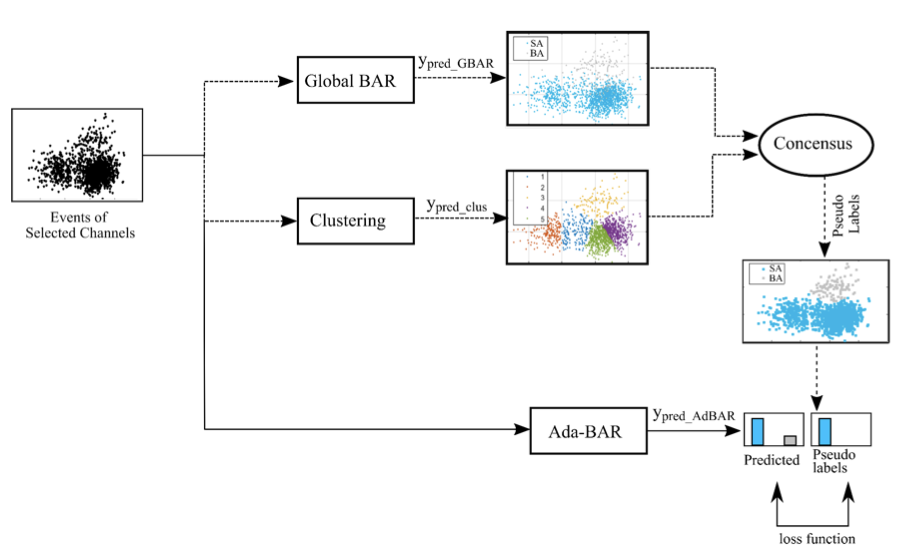
Muhammad Saif-ur-Rehman; Omair Ali; Christian Klaes; Ioannis Iossifidis
Adaptive SpikeDeep-Classifier: Self-organizing and self-supervised machine learning algorithm for online spike sorting Journal Article
In: arXiv:2304.01355 [cs, math, q-bio], 2023.
Links | BibTeX | Tags: BCI, Machine Learning, Spike Sorting
@article{saifurrehman2023adaptive,

title = {Adaptive SpikeDeep-Classifier: Self-organizing and self-supervised machine learning algorithm for online spike sorting},

author = {Muhammad Saif-ur-Rehman and Omair Ali and Christian Klaes and Ioannis Iossifidis},

doi = {10.48550/arXiv.2304.01355},

year  = {2023},

date = {2023-05-02},

urldate = {2023-05-02},

journal = {arXiv:2304.01355 [cs, math, q-bio]},

keywords = {BCI, Machine Learning, Spike Sorting},

pubstate = {published},

tppubtype = {article}

}
2022
Felix Grün; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis
Invariance to Quantile Selection in Distributional Continuous Control Journal Article
In: arXiv:2212.14262 [cs.LG], 2022.
Links | BibTeX | Tags: Artificial Intelligence (cs.AI), FOS: Computer and information sciences, I.2.6, I.2.8, Machine Learning, Machine Learning (cs.LG)
@article{grunInvarianceQuantileSelection2022,

title = {Invariance to Quantile Selection in Distributional Continuous Control},

author = {Felix Grün and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis},

url = {https://arxiv.org/abs/2212.14262},

doi = {10.48550/ARXIV.2212.14262},

year  = {2022},

date = {2022-12-29},

urldate = {2022-12-29},

journal = {arXiv:2212.14262 [cs.LG]},

keywords = {Artificial Intelligence (cs.AI), FOS: Computer and information sciences, I.2.6, I.2.8, Machine Learning, Machine Learning (cs.LG)},

pubstate = {published},

tppubtype = {article}

}
Stephan Johann Lehmler; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis
Deep transfer learning compared to subject-specific models for sEMG decoders Journal Article
In: Journal of Neural Engineering, 2022.
Links | BibTeX | Tags: BCI, Computational Complexity, Deep Transfer-Learning, Machine Learning, transfer learning
@article{lehmlerTransferLearningPatientSpecific2021bb,

title = {Deep transfer learning compared to subject-specific models for sEMG decoders},

author = {Stephan Johann Lehmler and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis},

url = {http://iopscience.iop.org/article/10.1088/1741-2552/ac9860},

doi = {10.1088/1741-2552/ac9860},

year  = {2022},

date = {2022-10-28},

urldate = {2022-10-28},

journal = {Journal of Neural Engineering},

keywords = {BCI, Computational Complexity, Deep Transfer-Learning, Machine Learning, transfer learning},

pubstate = {published},

tppubtype = {article}

}
Felix Grün; Ioannis Iossifidis
Exploring Distribution Parameterizations for Distributional Continuous Control Inproceedings
In: BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2022.
Links | BibTeX | Tags: Machine Learning, Reinforcement learning
@inproceedings{grunExploringDistributionParameterizations2022,

title = {Exploring Distribution Parameterizations for Distributional Continuous Control},

author = {Felix Grün and Ioannis Iossifidis},

doi = {10.12751/nncn.bc2022.112},

year  = {2022},

date = {2022-09-15},

urldate = {2022-09-15},

booktitle = {BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

keywords = {Machine Learning, Reinforcement learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Stephan Johann Lehmler; Muhammad Saif-ur-Rehman; Ioannis Iossifidis
Modeling Subject Specfic Surface EMG Features by Means of Deep Learning Inproceedings
In: BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2022.
Links | BibTeX | Tags: BCI, Machine Learning
@inproceedings{lehmlerModelingSubjectSpecfic2022,

title = {Modeling Subject Specfic Surface EMG Features by Means of Deep Learning},

author = {Stephan Johann Lehmler and Muhammad Saif-ur-Rehman and Ioannis Iossifidis},

doi = {10.12751/nncn.bc2022.309},

year  = {2022},

date = {2022-09-15},

urldate = {2022-09-15},

booktitle = {BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

keywords = {BCI, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Ioannis Iossifidis
Linking Muscle Activity and Motion Trajectory Inproceedings
In: BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2022.
Links | BibTeX | Tags: BCI, Machine Learning
@inproceedings{schmidtLinkingMuscleActivity2022,

title = {Linking Muscle Activity and Motion Trajectory},

author = {Marie Dominique Schmidt and Ioannis Iossifidis},

doi = {10.12751/nncn.bc2022.191},

year  = {2022},

date = {2022-09-15},

urldate = {2022-09-15},

booktitle = {BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

keywords = {BCI, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Tim Sziburis; Susanne Blex; Ioannis Iossifidis
A Dataset of 3D Hand Transport Trajectories Determined by Inertial Measurements from a Single Sensor Inproceedings
In: BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2022.
Links | BibTeX | Tags: BCI, Machine Learning
@inproceedings{sziburisDataset3DHand2022,

title = {A Dataset of 3D Hand Transport Trajectories Determined by Inertial Measurements from a Single Sensor},

author = {Tim Sziburis and Susanne Blex and Ioannis Iossifidis},

doi = {10.12751/nncn.bc2022.186},

year  = {2022},

date = {2022-09-15},

urldate = {2022-09-15},

booktitle = {BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

keywords = {BCI, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Aline Xavier Fidencio; Christian Klaes; Ioannis Iossifidis
Closed-Loop Adaptation of Brain-Machine Interfaces Using Error-Related Potentials and Reinforcement Learning Inproceedings
In: BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022, BCCN Bernstein Network Computational Network, 2022.
Links | BibTeX | Tags: BCI, Machine Learning
@inproceedings{xavierfidencioClosedloopAdaptationBrainmachine2022,

title = {Closed-Loop Adaptation of Brain-Machine Interfaces Using Error-Related Potentials and Reinforcement Learning},

author = {Aline Xavier Fidencio and Christian Klaes and Ioannis Iossifidis},

doi = {10.12751/nncn.bc2022.136},

year  = {2022},

date = {2022-09-15},

urldate = {2022-09-15},

booktitle = {BC22 : Computational Neuroscience & Neurotechnology Bernstein Conference 2022},

publisher = {BCCN Bernstein Network Computational Network},

keywords = {BCI, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Sebastian Doliwa; Muhammad Ayaz Hussain; Tim Sziburis; Ioannis Iossifidis
Biologically Inspired Model for Timed Motion in Robotic Systems Inproceedings
In: 9th IEEE RAS/EMBS International Conference on Biomedical Robotics & Biomechatronics, IEEE, Seoul, South Korea, 2022.
BibTeX | Tags: dynamical systems, Robotics
@inproceedings{doliwaBiologicallyInspiredModel2022,

title = {Biologically Inspired Model for Timed Motion in Robotic Systems},

author = {Sebastian Doliwa and Muhammad Ayaz Hussain and Tim Sziburis and Ioannis Iossifidis},

year  = {2022},

date = {2022-08-12},

urldate = {2022-08-12},

booktitle = {9th IEEE RAS/EMBS International Conference on Biomedical Robotics & Biomechatronics},

publisher = {IEEE},

address = {Seoul, South Korea},

keywords = {dynamical systems, Robotics},

pubstate = {published},

tppubtype = {inproceedings}

}
Aline Xavier Fidencio; Christian Klaes; Ioannis Iossifidis
Error-Related Potentials in Reinforcement Learning-Based Brain-Machine Interfaces Journal Article
In: Frontiers in Human Neuroscience, vol. 16, 2022.
Abstract | Links | BibTeX | Tags: BCI, EEG, error-related potentials, Machine Learning, Reinforcement learning
@article{xavierfidencioErrorrelated,

title = {Error-Related Potentials in Reinforcement Learning-Based Brain-Machine Interfaces},

author = {Aline Xavier Fidencio and Christian Klaes and Ioannis Iossifidis},

url = {https://www.frontiersin.org/article/10.3389/fnhum.2022.806517},

doi = {https://doi.org/10.3389/fnhum.2022.806517},

year  = {2022},

date = {2022-06-24},

urldate = {2022-06-24},

journal = {Frontiers in Human Neuroscience},

volume = {16},

abstract = {The human brain has been an object of extensive investigation in different fields. While several studies have focused on understanding the neural correlates of error processing, advances in brain-machine interface systems using non-invasive techniques further enabled the use of the measured signals in different applications. The possibility of detecting these error-related potentials (ErrPs) under different experimental setups on a single-trial basis has further increased interest in their integration in closed-loop settings to improve system performance, for example, by performing error correction. Fewer works have, however, aimed at reducing future mistakes or learning. We present a review focused on the current literature using non-invasive systems that have combined the ErrPs information specifically in a reinforcement learning framework to go beyond error correction and have used these signals for learning.},

keywords = {BCI, EEG, error-related potentials, Machine Learning, Reinforcement learning},

pubstate = {published},

tppubtype = {article}

}
Omair Ali; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis; Christian Klaes
ConTraNet: A Single End-to-End Hybrid Network for EEG-based and EMG-based Human Machine Interfaces Journal Article
In: 2022.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning, neural processing, signal processing
@article{aliConTraNetSingleEndtoend2022b,

title = {ConTraNet: A Single End-to-End Hybrid Network for EEG-based and EMG-based Human Machine Interfaces},

author = {Omair Ali and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis and Christian Klaes},

url = {http://arxiv.org/abs/2206.10677},

doi = {10.48550/arXiv.2206.10677},

year  = {2022},

date = {2022-06-21},

urldate = {2022-06-21},

abstract = {Objective: Electroencephalography (EEG) and electromyography (EMG) are two non-invasive bio-signals, which are widely used in human machine interface (HMI) technologies (EEG-HMI and EMG-HMI paradigm) for the rehabilitation of physically disabled people. Successful decoding of EEG and EMG signals into respective control command is a pivotal step in the rehabilitation process. Recently, several Convolutional neural networks (CNNs) based architectures are proposed that directly map the raw time-series signal into decision space and the process of meaningful features extraction and classification are performed simultaneously. However, these networks are tailored to the learn the expected characteristics of the given bio-signal and are limited to single paradigm. In this work, we addressed the question that can we build a single architecture which is able to learn distinct features from different HMI paradigms and still successfully classify them. Approach: In this work, we introduce a single hybrid model called ConTraNet, which is based on CNN and Transformer architectures that is equally useful for EEG-HMI and EMG-HMI paradigms. ConTraNet uses CNN block to introduce inductive bias in the model and learn local dependencies, whereas the Transformer block uses the self-attention mechanism to learn the long-range dependencies in the signal, which are crucial for the classification of EEG and EMG signals. Main results: We evaluated and compared the ConTraNet with state-of-the-art methods on three publicly available datasets which belong to EEG-HMI and EMG-HMI paradigms. ConTraNet outperformed its counterparts in all the different category tasks (2-class, 3-class, 4-class, and 10-class decoding tasks). Significance: The results suggest that ConTraNet is robust to learn distinct features from different HMI paradigms and generalizes well as compared to the current state of the art algorithms.},

keywords = {BCI, Machine Learning, neural processing, signal processing},

pubstate = {published},

tppubtype = {article}

}
Omair Ali; Muhammad Saif-ur-Rehman; Tobias Glasmachers; Ioannis Iossifidis; Christian Klaes
ConTraNet: A Single End-to-End Hybrid Network for EEG-based and EMG-based Human Machine Interfaces Journal Article
In: arXiv:2206.10677 [q-bio.NC], 2022.
Abstract | Links | BibTeX | Tags: BCI, Machine Learning, neural processing, signal processing
@article{aliConTraNetSingleEndtoend2022,

title = {ConTraNet: A Single End-to-End Hybrid Network for EEG-based and EMG-based Human Machine Interfaces},

author = {Omair Ali and Muhammad Saif-ur-Rehman and Tobias Glasmachers and Ioannis Iossifidis and Christian Klaes},

url = {http://arxiv.org/abs/2206.10677},

doi = {10.48550/arXiv.2206.10677},

year  = {2022},

date = {2022-06-21},

urldate = {2022-06-21},

journal = {arXiv:2206.10677 [q-bio.NC]},

abstract = {Objective: Electroencephalography (EEG) and electromyography (EMG) are two non-invasive bio-signals, which are widely used in human machine interface (HMI) technologies (EEG-HMI and EMG-HMI paradigm) for the rehabilitation of physically disabled people. Successful decoding of EEG and EMG signals into respective control command is a pivotal step in the rehabilitation process. Recently, several Convolutional neural networks (CNNs) based architectures are proposed that directly map the raw time-series signal into decision space and the process of meaningful features extraction and classification are performed simultaneously. However, these networks are tailored to the learn the expected characteristics of the given bio-signal and are limited to single paradigm. In this work, we addressed the question that can we build a single architecture which is able to learn distinct features from different HMI paradigms and still successfully classify them. Approach: In this work, we introduce a single hybrid model called ConTraNet, which is based on CNN and Transformer architectures that is equally useful for EEG-HMI and EMG-HMI paradigms. ConTraNet uses CNN block to introduce inductive bias in the model and learn local dependencies, whereas the Transformer block uses the self-attention mechanism to learn the long-range dependencies in the signal, which are crucial for the classification of EEG and EMG signals. Main results: We evaluated and compared the ConTraNet with state-of-the-art methods on three publicly available datasets which belong to EEG-HMI and EMG-HMI paradigms. ConTraNet outperformed its counterparts in all the different category tasks (2-class, 3-class, 4-class, and 10-class decoding tasks). Significance: The results suggest that ConTraNet is robust to learn distinct features from different HMI paradigms and generalizes well as compared to the current state of the art algorithms.},

keywords = {BCI, Machine Learning, neural processing, signal processing},

pubstate = {published},

tppubtype = {article}

}
Sebastian Doliwa; Andreas Erbeslöh; Karsten Seidl; Ioannis Iossifidis
Development of a Scalable Analog Front-End for Brain-Computer Interfaces Inproceedings
In: 17th International Conference on PhD Research in Microelectronics and Electronics, IEEE Prime 2022, Sardinia, Italy, 2022.
BibTeX | Tags: BCI, Implantable BCI
@inproceedings{doliwaDevelopmentScalableAnalogacceptedb,

title = {Development of a Scalable Analog Front-End for Brain-Computer Interfaces},

author = {Sebastian Doliwa and Andreas Erbeslöh and Karsten Seidl and Ioannis Iossifidis},

year  = {2022},

date = {2022-06-15},

urldate = {2022-06-15},

booktitle = {17th International Conference on PhD Research in Microelectronics and Electronics},

publisher = {IEEE Prime 2022},

address = {Sardinia, Italy},

keywords = {BCI, Implantable BCI},

pubstate = {published},

tppubtype = {inproceedings}

}
Sebastian Doliwa; Andreas Erbeslöh; Karsten Seidl; Ioannis Iossifidis
Development of a Scalable Analog Front-End for Brain-Computer Interfaces Inproceedings
In: 17th International Conference on PhD Research in Microelectronics and Electronics, IEEE Prime 2022, Sardinia, Italy, 2022.
Links | BibTeX | Tags: BCI, Implantable BCI
@inproceedings{doliwaDevelopmentScalableAnalogaccepted,

title = {Development of a Scalable Analog Front-End for Brain-Computer Interfaces},

author = {Sebastian Doliwa and Andreas Erbeslöh and Karsten Seidl and Ioannis Iossifidis},

doi = {10.1109/PRIME55000.2022.9816757},

year  = {2022},

date = {2022-06-15},

urldate = {2022-06-15},

booktitle = {17th International Conference on PhD Research in Microelectronics and Electronics},

publisher = {IEEE Prime 2022},

address = {Sardinia, Italy},

keywords = {BCI, Implantable BCI},

pubstate = {published},

tppubtype = {inproceedings}

}
Omair Ali; Muhammad Saif-ur-Rehman; Susanne Dyck; Tobias Glasmachers; Ioannis Iossifidis; Christian Klaes
Enhancing the decoding accuracy of EEG signals by the introduction of anchored-STFT and adversarial data augmentation method Journal Article
In: Nature Scientific Reports, vol. 12, iss. 1, pp. 4245, 2022, ISSN: 2045-2322.
Abstract | Links | BibTeX | Tags: Adversarial NN, BCI, computer science, EEG, Machine Learning, Quantitative Biology, Quantitative Methods
@article{aliAnchoredSTFTGNAAExtension2021ab,

title = {Enhancing the decoding accuracy of EEG signals by the introduction of anchored-STFT and adversarial data augmentation method},

author = {Omair Ali and Muhammad Saif-ur-Rehman and Susanne Dyck and Tobias Glasmachers and Ioannis Iossifidis and Christian Klaes},

url = {https://www.nature.com/articles/s41598-022-07992-w},

doi = {https://doi.org/10.1038/s41598-022-07992-w},

issn = {2045-2322},

year  = {2022},

date = {2022-03-10},

urldate = {2022-03-10},

journal = {Nature Scientific Reports},

volume = {12},

issue = {1},

pages = {4245},

abstract = {Brain-computer interfaces (BCIs) enable communication between humans and machines by translating brain activity into control commands. Electroencephalography (EEG) signals are one of the most used brain signals in non-invasive BCI applications but are often contaminated with noise. Therefore, it is possible that meaningful patterns for classifying EEG signals are deeply hidden. State-of-the-art deep-learning algorithms are successful in learning hidden, meaningful patterns. However, the quality and the quantity of the presented inputs is pivotal. Here, we propose a novel feature extraction method called anchored Short Time Fourier Transform (anchored-STFT), which is an advanced version of STFT, as it minimizes the trade-off between temporal and spectral resolution presented by STFT. In addition, we propose a novel augmentation method, called gradient norm adversarial augmentation (GNAA). GNAA is not only an augmentation method but is also used to harness adversarial inputs in EEG data, which not only improves the classification accuracy but also enhances the robustness of the classifier. In addition, we also propose a new CNN architecture, namely Skip-Net, for the classification of EEG signals. The proposed pipeline outperforms all state-of-the-art methods and yields an average classification accuracy of 90.7 % and 89.54 % on BCI competition II dataset III and BCI competition IV dataset 2b, respectively.},

keywords = {Adversarial NN, BCI, computer science, EEG, Machine Learning, Quantitative Biology, Quantitative Methods},

pubstate = {published},

tppubtype = {article}

}
Omair Ali; Muhammad Saif-ur-Rehman; Susanne Dyck; Tobias Glasmachers; Ioannis Iossifidis; Christian Klaes
Enhancing the decoding accuracy of EEG signals by the introduction of anchored-STFT and adversarial data augmentation method Journal Article
In: Nature Scientific Reports, vol. 12, iss. 1, pp. 4245, 2022, ISSN: 2045-2322.
Abstract | Links | BibTeX | Tags: Adversarial NN, BCI, computer science, EEG, Machine Learning, Quantitative Biology, Quantitative Methods
@article{aliAnchoredSTFTGNAAExtension2021a,

title = {Enhancing the decoding accuracy of EEG signals by the introduction of anchored-STFT and adversarial data augmentation method},

author = {Omair Ali and Muhammad Saif-ur-Rehman and Susanne Dyck and Tobias Glasmachers and Ioannis Iossifidis and Christian Klaes},

url = {https://www.nature.com/articles/s41598-022-07992-w},

doi = {https://doi.org/10.1038/s41598-022-07992-w},

issn = {2045-2322},

year  = {2022},

date = {2022-03-10},

urldate = {2022-03-10},

journal = {Nature Scientific Reports},

volume = {12},

issue = {1},

pages = {4245},

abstract = {Brain-computer interfaces (BCIs) enable communication between humans and machines by translating brain activity into control commands. Electroencephalography (EEG) signals are one of the most used brain signals in non-invasive BCI applications but are often contaminated with noise. Therefore, it is possible that meaningful patterns for classifying EEG signals are deeply hidden. State-of-the-art deep-learning algorithms are successful in learning hidden, meaningful patterns. However, the quality and the quantity of the presented inputs is pivotal. Here, we propose a novel feature extraction method called anchored Short Time Fourier Transform (anchored-STFT), which is an advanced version of STFT, as it minimizes the trade-off between temporal and spectral resolution presented by STFT. In addition, we propose a novel augmentation method, called gradient norm adversarial augmentation (GNAA). GNAA is not only an augmentation method but is also used to harness adversarial inputs in EEG data, which not only improves the classification accuracy but also enhances the robustness of the classifier. In addition, we also propose a new CNN architecture, namely Skip-Net, for the classification of EEG signals. The proposed pipeline outperforms all state-of-the-art methods and yields an average classification accuracy of 90.7 % and 89.54 % on BCI competition II dataset III and BCI competition IV dataset 2b, respectively.},

keywords = {Adversarial NN, BCI, computer science, EEG, Machine Learning, Quantitative Biology, Quantitative Methods},

pubstate = {published},

tppubtype = {article}

}
Marie Dominique Schmidt; Tobias Glasmachers; Ioannis Iossifidis
From Motion to Muscle Journal Article
In: arXiv: 2201.11501 [cs.LG], 2022.
Links | BibTeX | Tags: BCI, Machine Learning, movement model, muscle signal generator, recurrent neural network
@article{schmidt2022motionb,

title = {From Motion to Muscle},

author = {Marie Dominique Schmidt and Tobias Glasmachers and Ioannis Iossifidis},

doi = {https://doi.org/10.48550/arXiv.2201.11501},

year  = {2022},

date = {2022-01-01},

urldate = {2022-01-01},

journal = {arXiv: 2201.11501 [cs.LG]},

keywords = {BCI, Machine Learning, movement model, muscle signal generator, recurrent neural network},

pubstate = {published},

tppubtype = {article}

}
Aline Xavier Fidencio; Tobias Glasmachers; Ioannis Iossifidis
Error-Related Potentials Detection with Dry- and Wet-Electrode EEG Inproceedings
In: FENS, Forum 2022, FENS, Federation of European Neuroscience Societies, 2022.
Abstract | BibTeX | Tags: BCI, EEG, error-related potentials, Machine Learning
@inproceedings{fidencioErrorrelatedPotentialsDetection2022b,

title = {Error-Related Potentials Detection with Dry- and Wet-Electrode EEG},

author = {Aline Xavier Fidencio and Tobias Glasmachers and Ioannis Iossifidis},

year  = {2022},

date = {2022-01-01},

urldate = {2022-01-01},

booktitle = {FENS, Forum 2022},

publisher = {FENS, Federation of European Neuroscience Societies},

abstract = {Electroencephalography (EEG) is a non-invasive technique for measuring brain electrical activity from electrodes placed on the scalp surface. Improvements in this technology are particularly relevant because they also boost brain-machine interfaces (BMI) development. Commonly, gel-based electrodes are used since they guarantee a high-quality signal. Alternatively, dry electrodes have been introduced, more suitable for daily use. In this work, we compare conventional dry and wet electrode systems specifically for the detection of error-related potentials (ErrPs). ErrPs are elicited as a reaction to both self-made and external errors. There has been increased interest in the integration of these signals into BMIs to improve their performance since they provide a convenient source of feedback to the system with no extra workload for the subject. These signals can be used, e.g., to correct errors or even for system adaptation. ErrP-based BMIs in the literature have consistently used wet electrodes. Therefore, even though both electrodes types have been compared for other event-related potentials (e.g., P300), it is relevant to know whether the signal quality for the detection of ErrPs is comparable among them. In this work, we implement a simple game to elicit ErrPs and compare the quality of the measured signals. We tested the feasibility of the experimental protocol to elicit ErrP and the measured ErrP displayed a similar waveshape in terms of observed peaks. However, differences exist in both latencies as well as in their amplitude. These variations and other relevant characteristics have to be further verified with more subjects},

keywords = {BCI, EEG, error-related potentials, Machine Learning},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Tobias Glasmachers; Ioannis Iossifidis
Motion Intention Prediction Inproceedings
In: FENS, Forum 2022, FENS, Federation of European Neuroscience Societies, 2022.
Abstract | BibTeX | Tags: BCI, Machine Learning, movement model, muscle signal generator, recurrent neural network
@inproceedings{schmidtMotionIntentionPrediction2022ab,

title = {Motion Intention Prediction},

author = {Marie Dominique Schmidt and Tobias Glasmachers and Ioannis Iossifidis},

year  = {2022},

date = {2022-01-01},

urldate = {2022-01-01},

booktitle = {FENS, Forum 2022},

publisher = {FENS, Federation of European Neuroscience Societies},

abstract = {Motion intention prediction is the key to robot-assisted rehabilitation systems. These can rely on various biological signals. One commonly used signal is the muscle activity measured by an electromyogram that occurs between 50-100 milliseconds before the actual movement, allowing a real-world application to assist in time. We show that upper limb motion can be estimated from the corresponding muscle activity. To this end, eight-arm muscles are mapped to the joint angle, velocity, and acceleration of the shoulder, elbow, and wrist. For this purpose, we specifically develop an artificial neural network that estimates complex motions involving multiple upper limb joints. The network model is evaluated concerning its ability to generalize across subjects as well as for new motions. This is achieved through training on multiple subjects and additional transfer learning methods so that the prediction for new subjects is significantly improved. In particular, this is beneficial for a robust real-world application. Furthermore, we investigate the importance of the different parameters such as angle, velocity, and acceleration for simple and complex motions. Predictions for simple motions along with the main components of complex motions achieve excellent accuracy while joints that do not play a dominant role during the motion have comparatively lower accuracy.},

keywords = {BCI, Machine Learning, movement model, muscle signal generator, recurrent neural network},

pubstate = {published},

tppubtype = {inproceedings}

}
Marie Dominique Schmidt; Tobias Glasmachers; Ioannis Iossifidis
From Motion to Muscle Journal Article
In: arXiv: 2201.11501 [cs.LG], 2022.
Links | BibTeX | Tags: BCI, Machine Learning, movement model, muscle signal generator, recurrent neural network
@article{schmidt2022motion,

title = {From Motion to Muscle},

author = {Marie Dominique Schmidt and Tobias Glasmachers and Ioannis Iossifidis},

doi = {https://doi.org/10.48550/arXiv.2201.11501},

year  = {2022},

date = {2022-01-01},

urldate = {2022-01-01},

journal = {arXiv: 2201.11501 [cs.LG]},

keywords = {BCI, Machine Learning, movement model, muscle signal generator, recurrent neural network},

pubstate = {published},

tppubtype = {article}

}